Data Collection
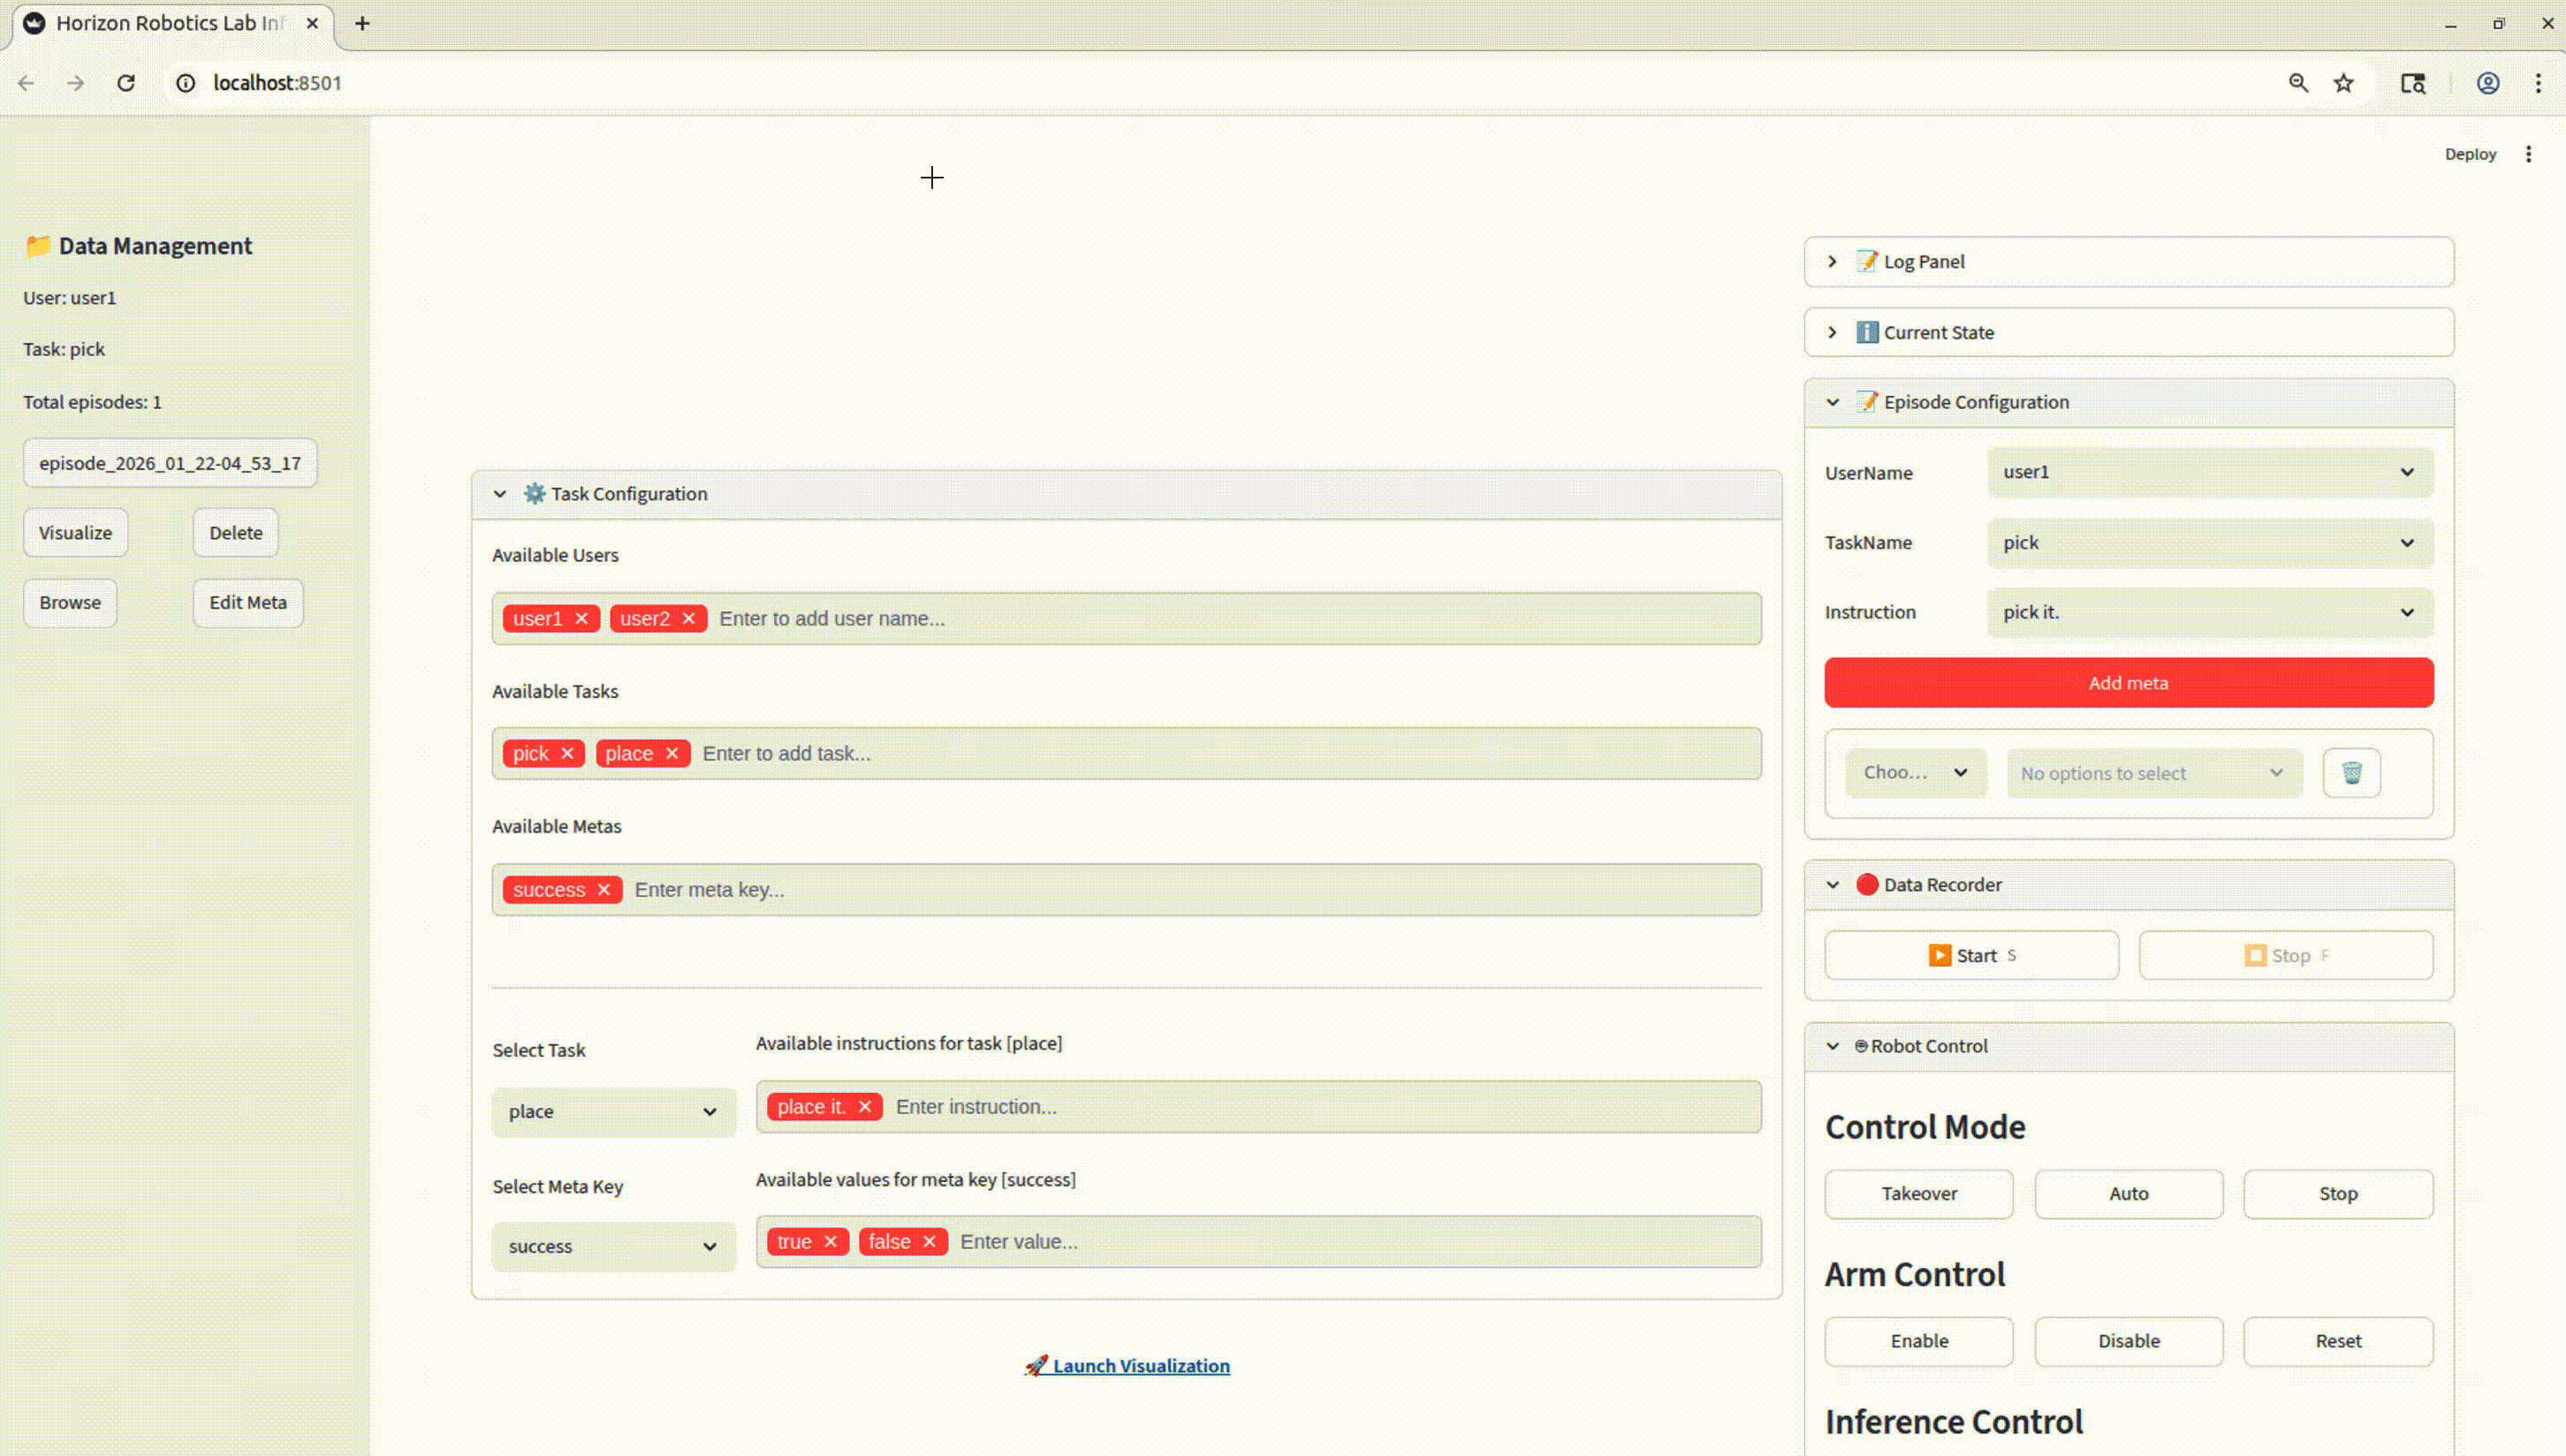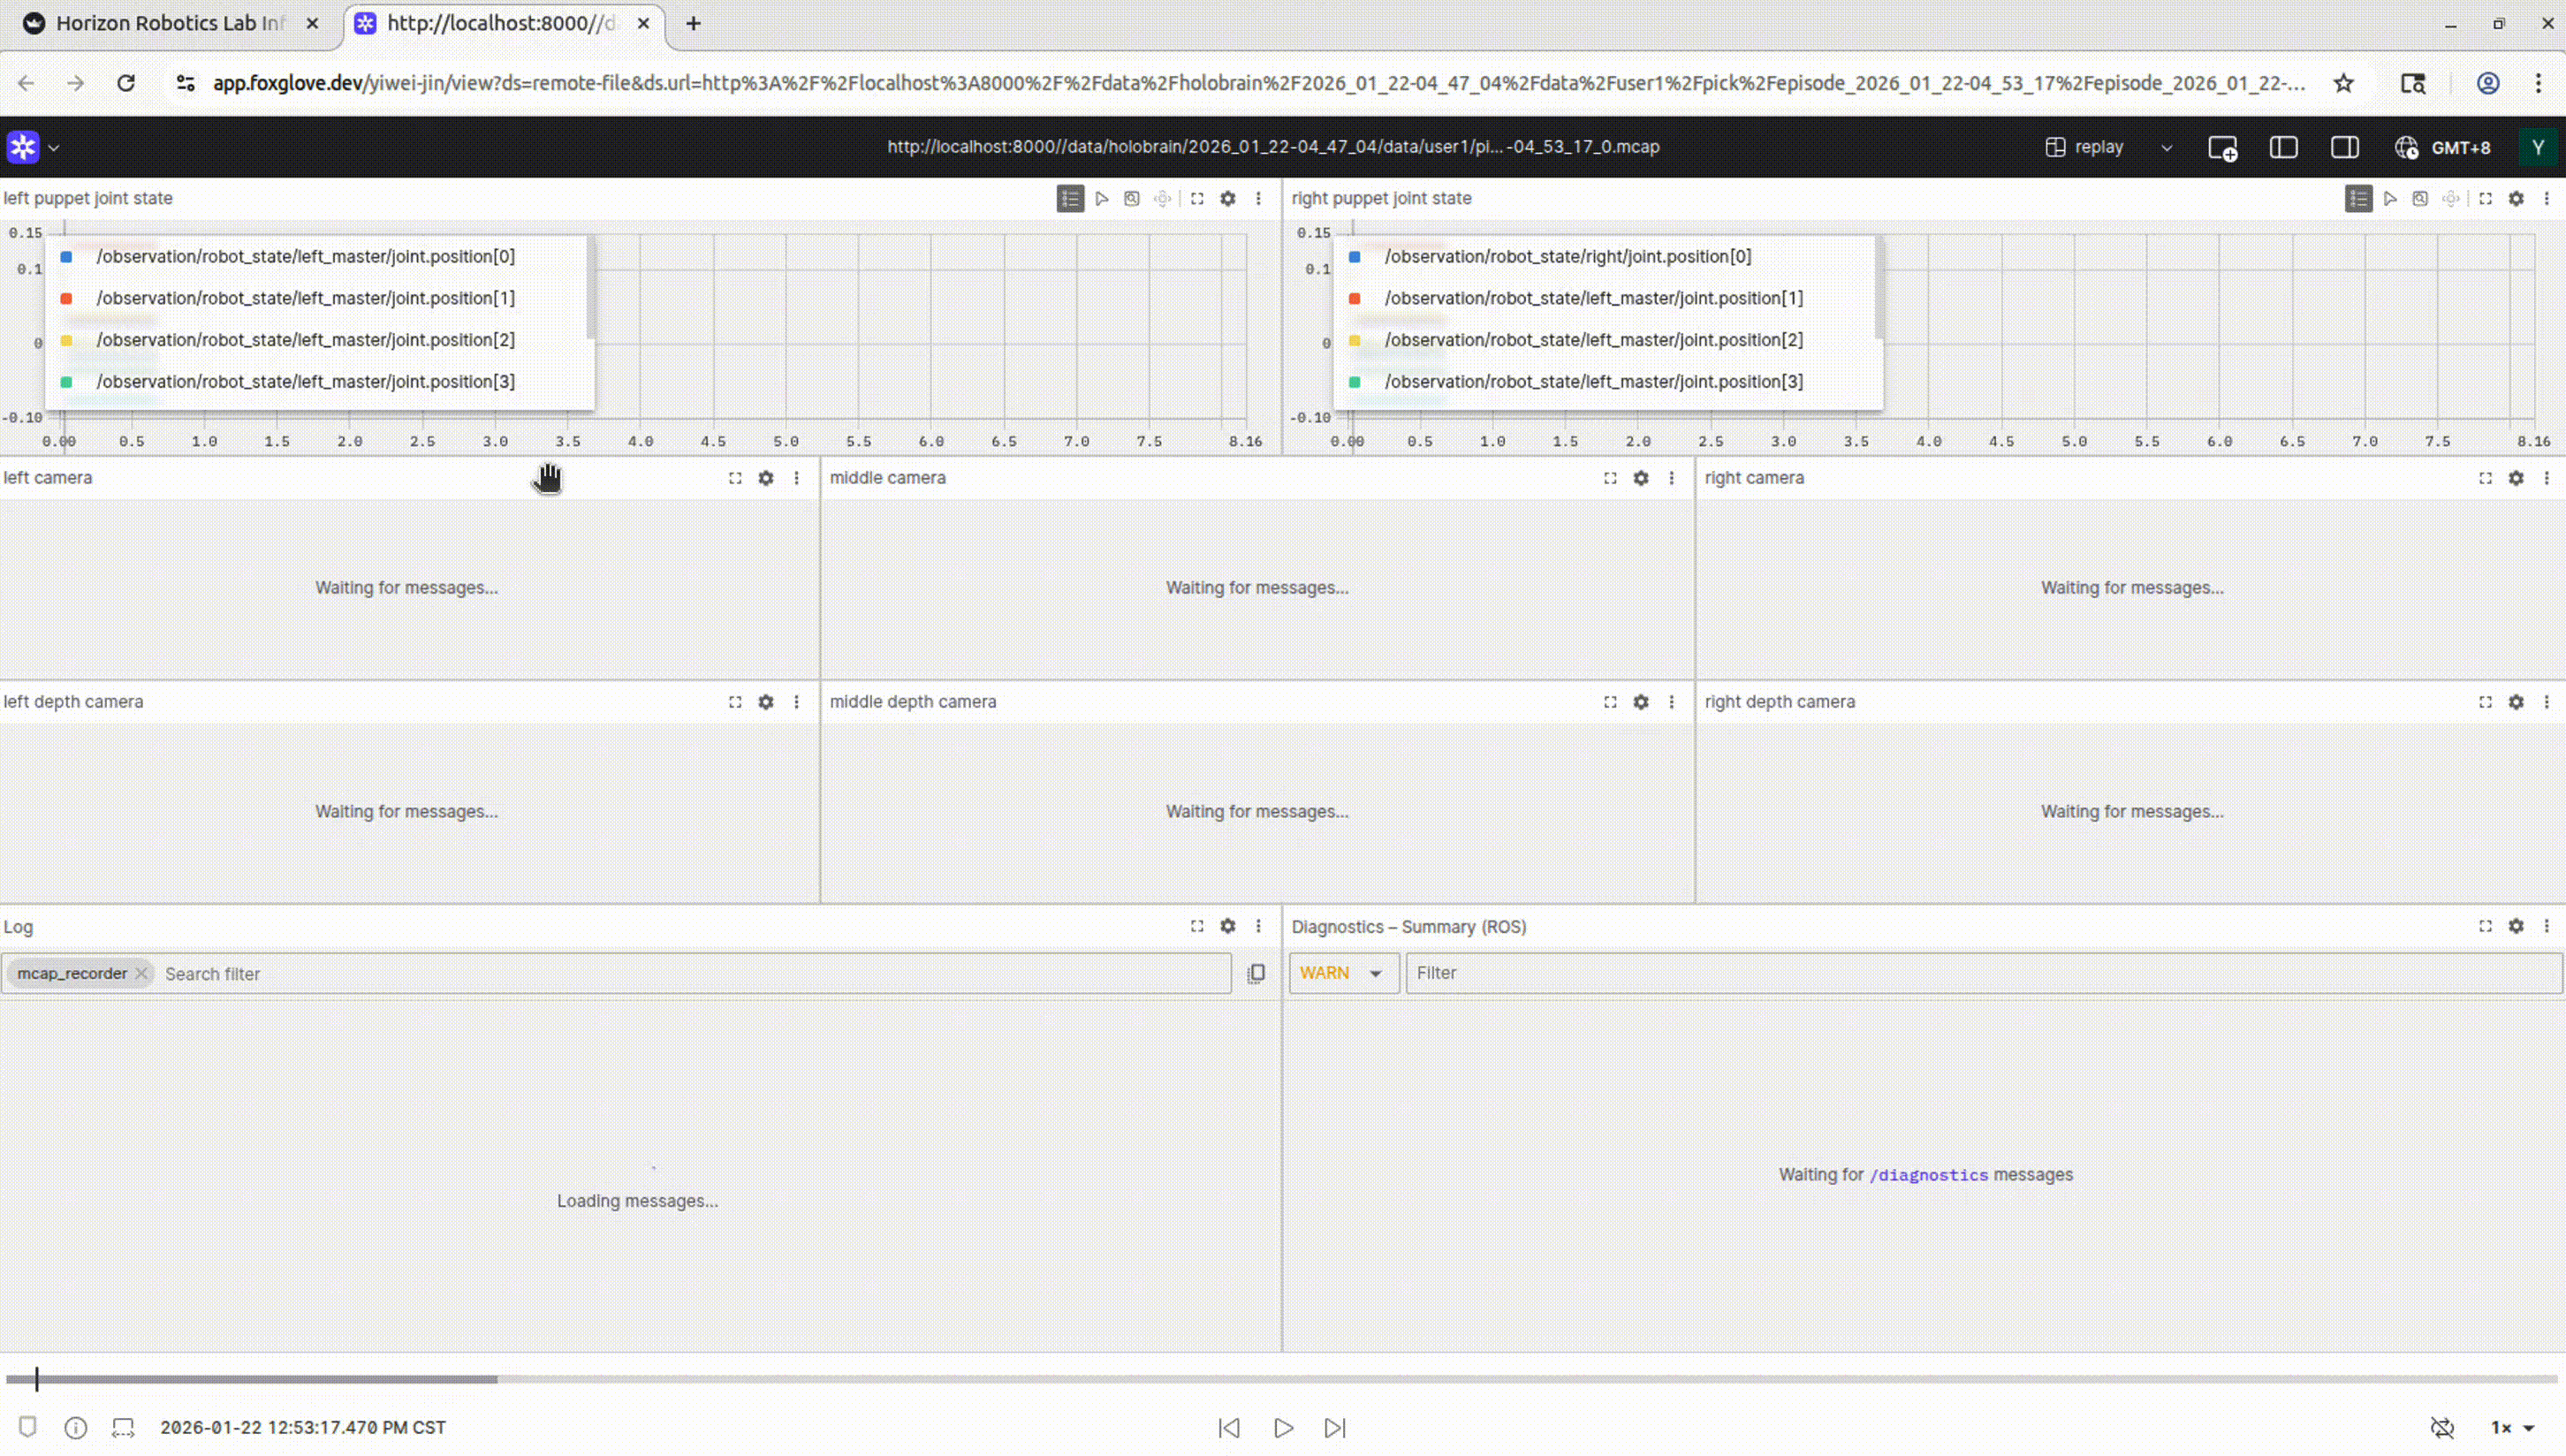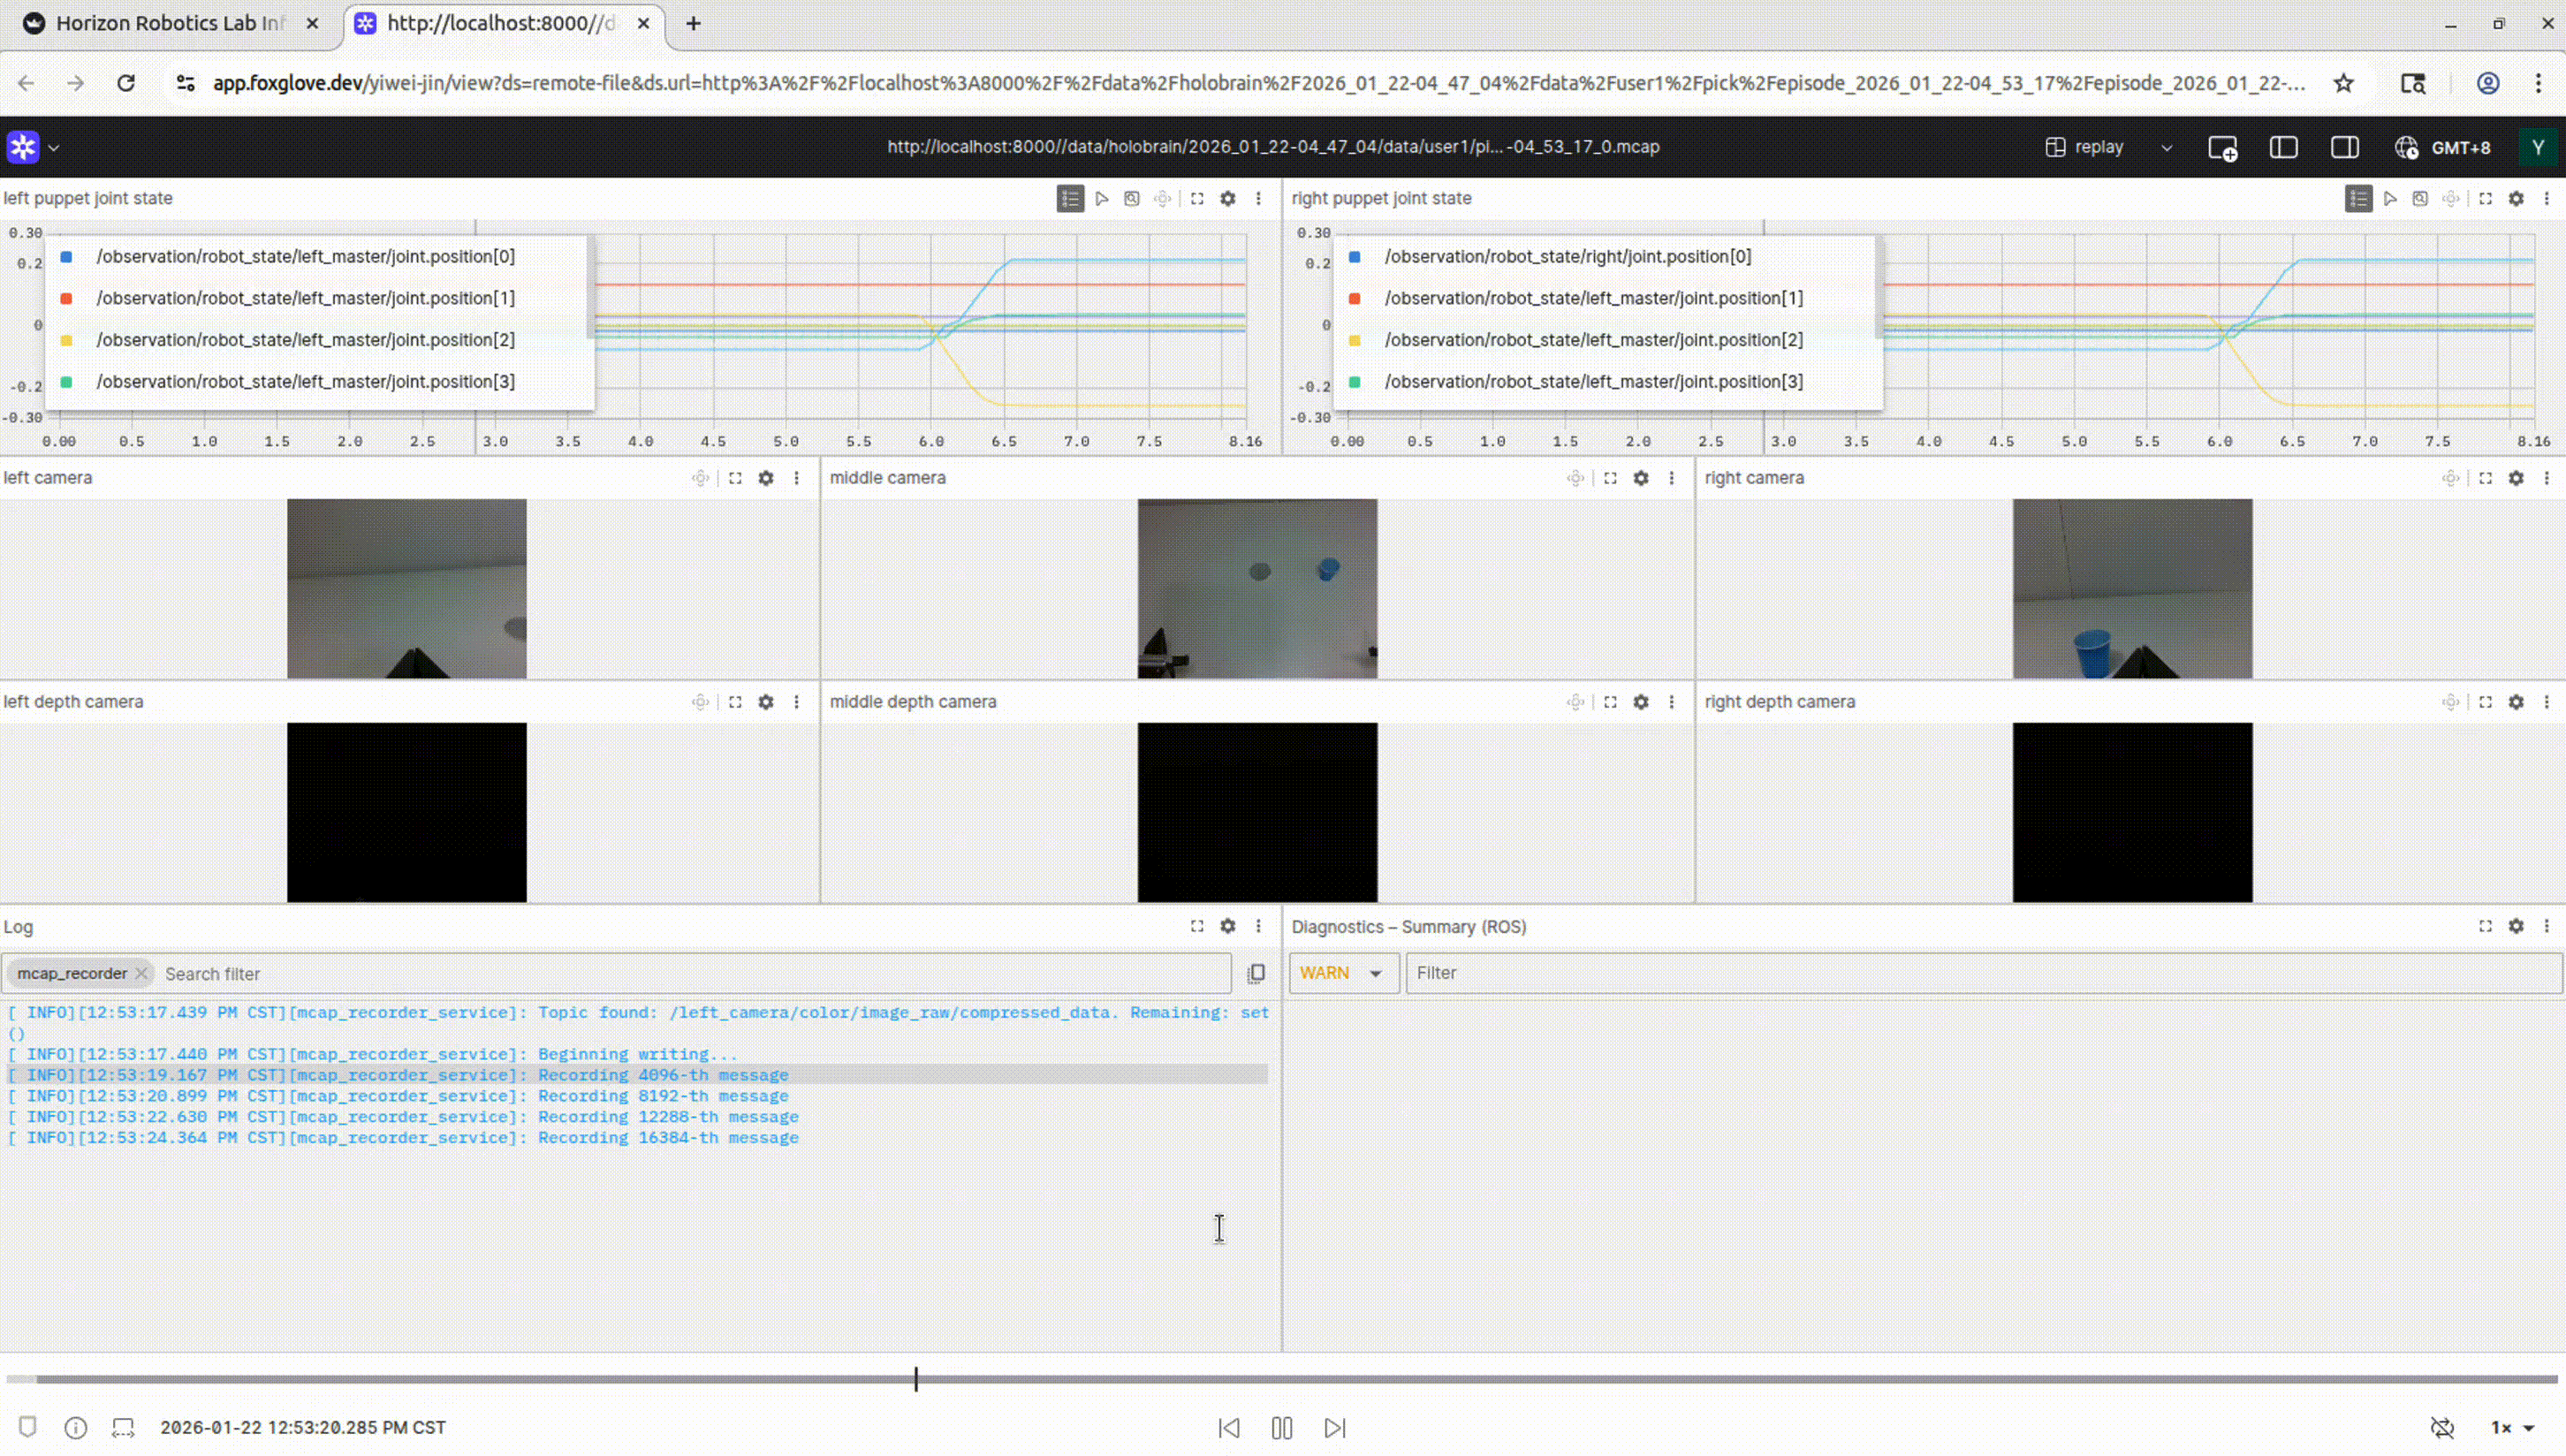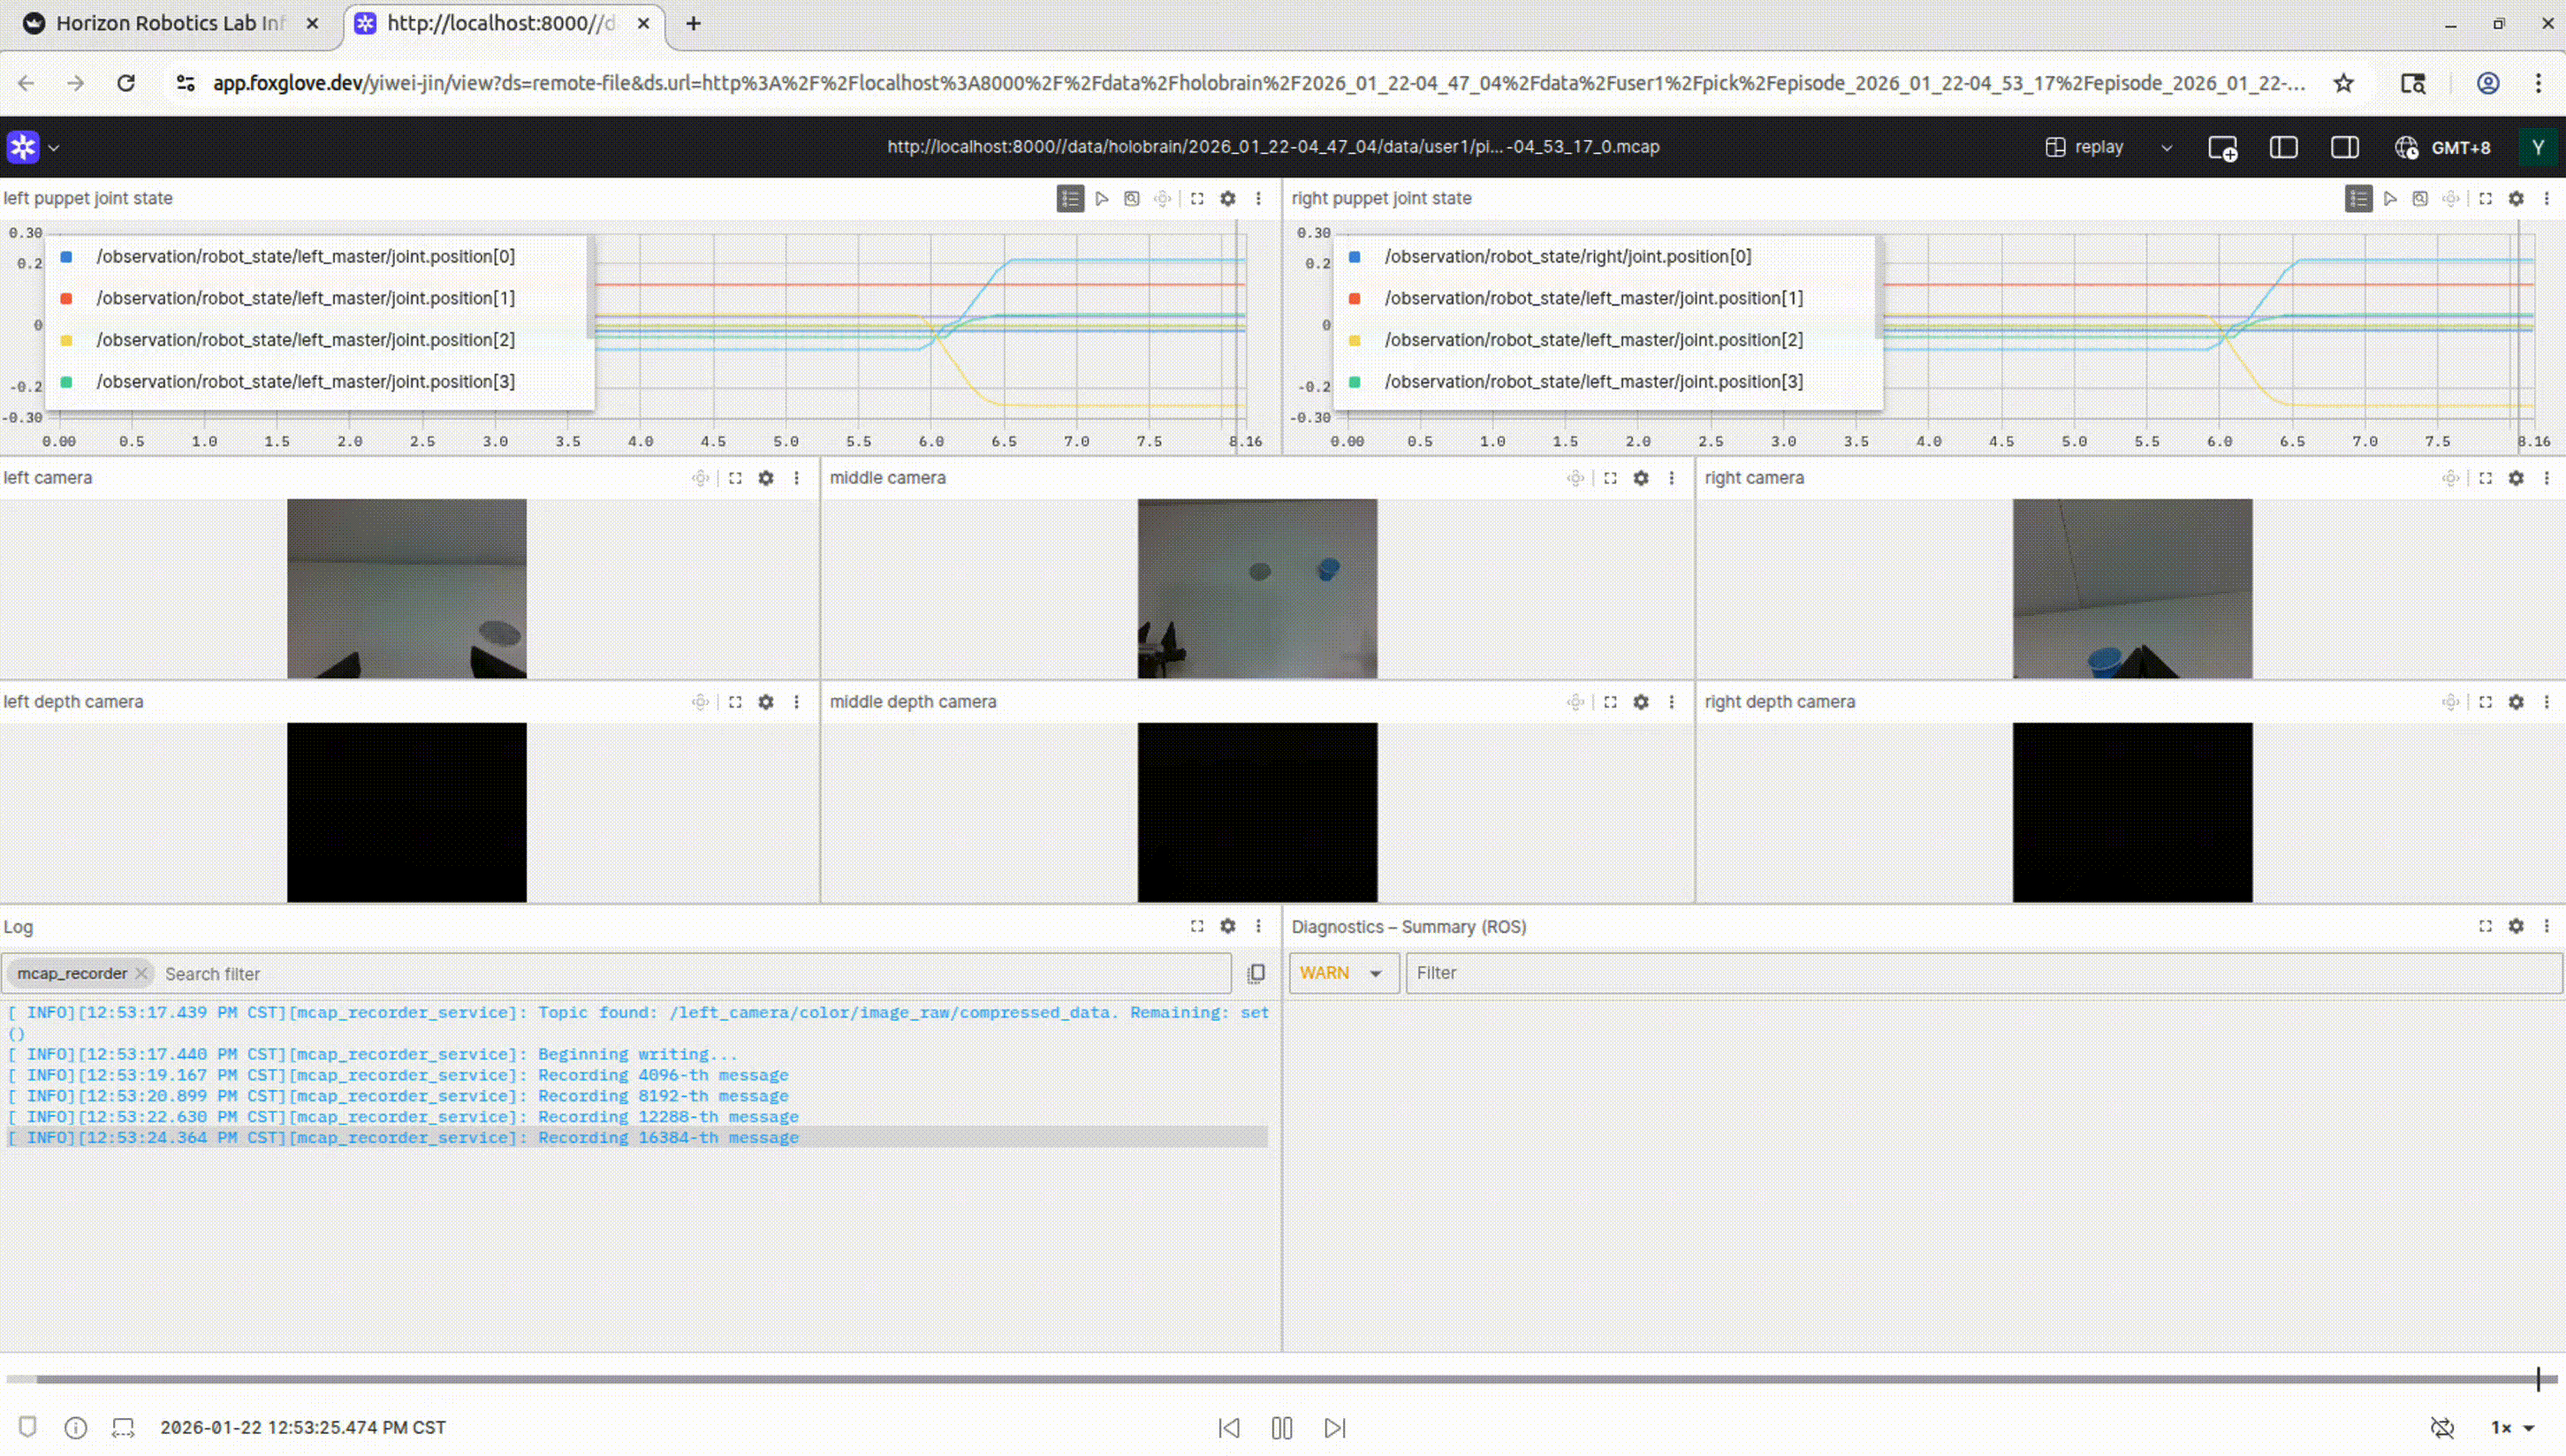
We developed an mcap-based (mcap.dev) data collection system that records both expert demonstrations and on-policy model rollouts.
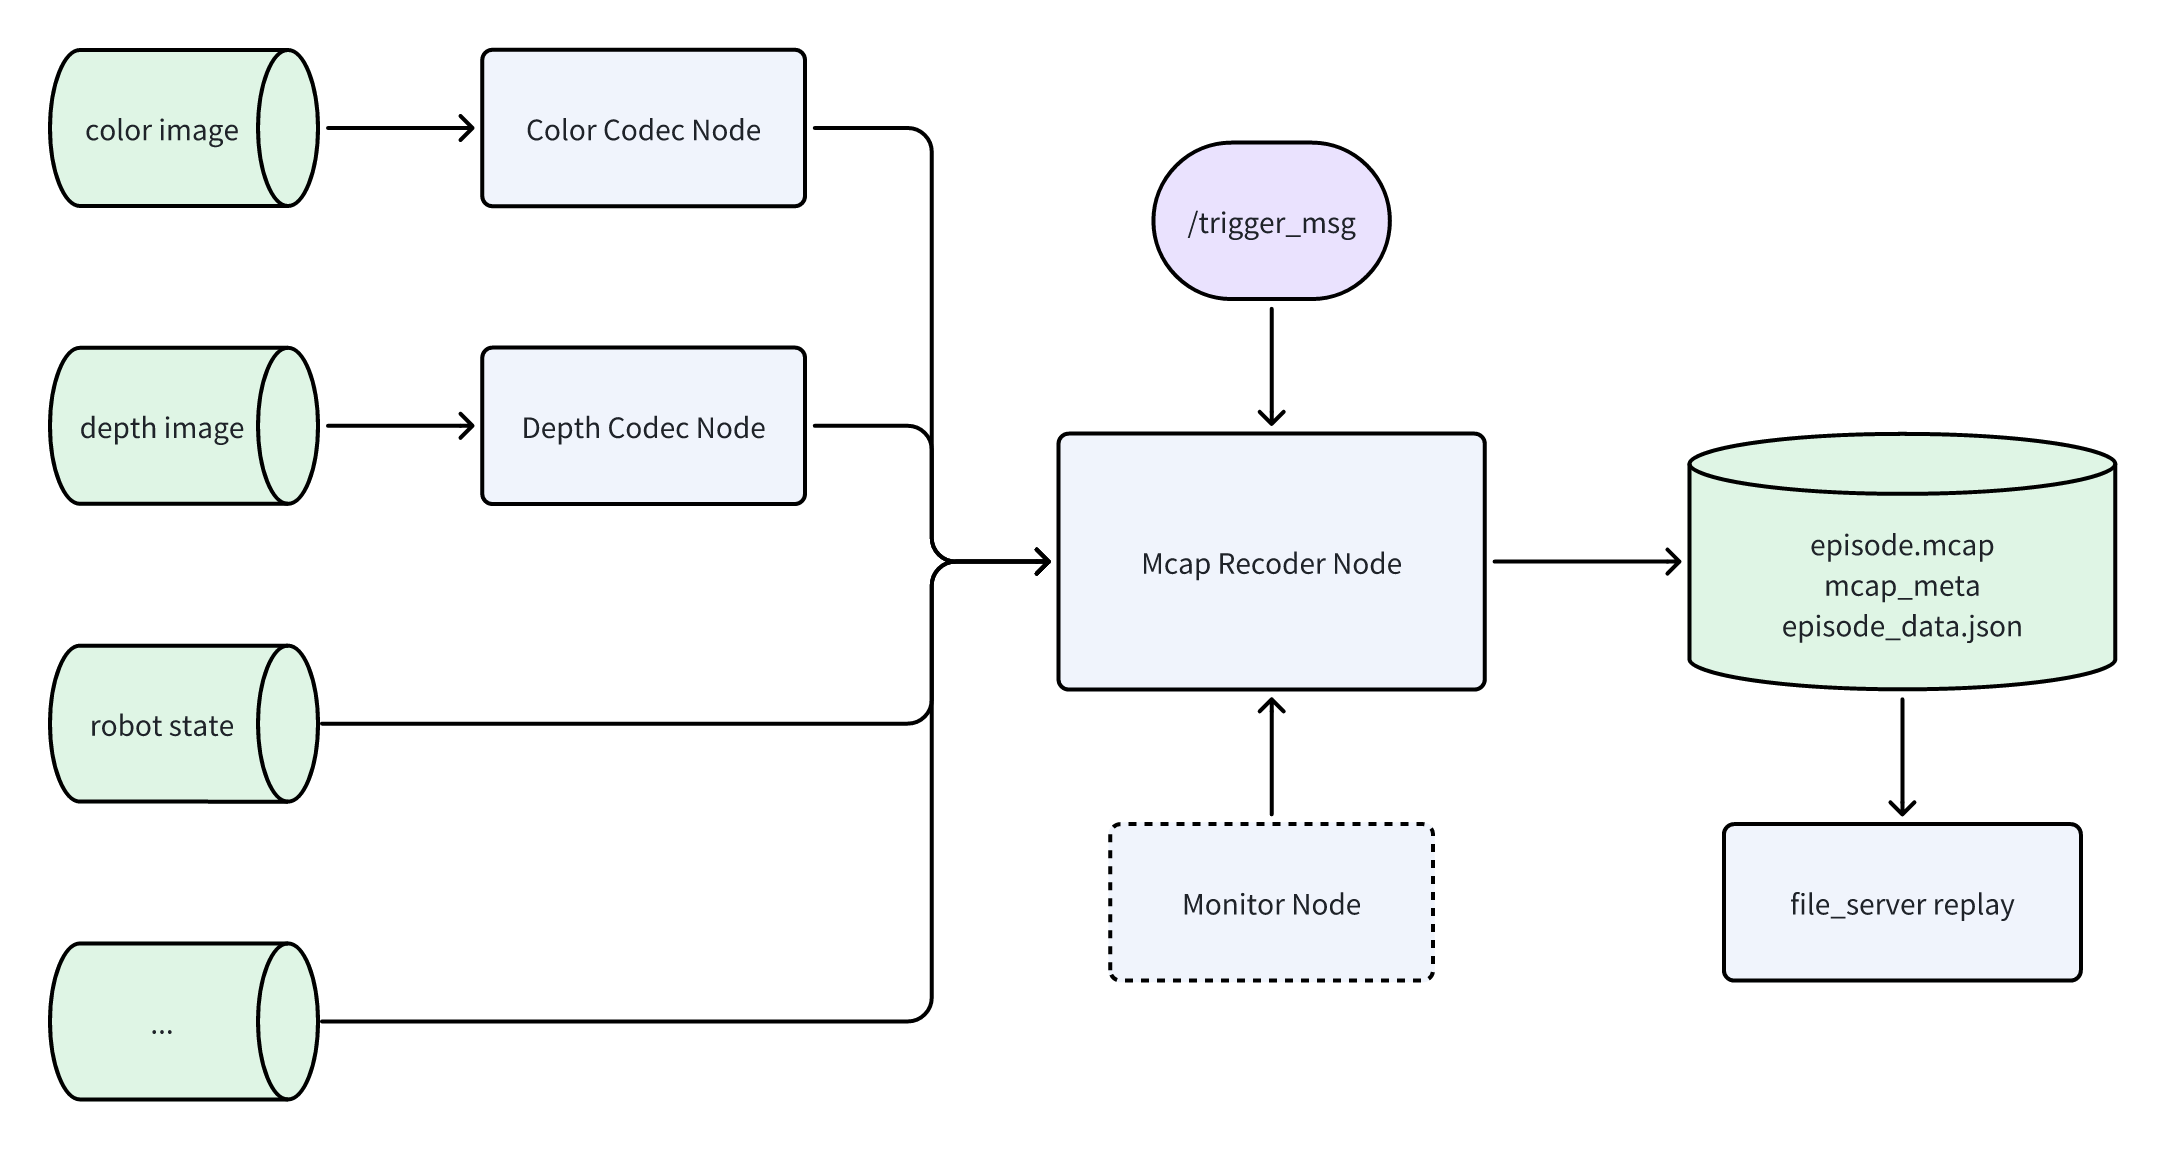
Data Collection Flowchart
1. Structured Data & Metadata Management
Comprehensive Annotation: The system supports detailed annotation management, allowing for the explicit definition of user identities, task names, and specific task instructions.
Hierarchical Data Organization: Recorded data is structured systematically following the directory logic:
{app_init_time}/{username}/{task_name}/{episode_timestamp}. Each episode package includes:Raw
MCAPdata files.Associated
mcap_metafor stream indexing.An extended
episode_meta.jsonfor high-level experiment metadata.
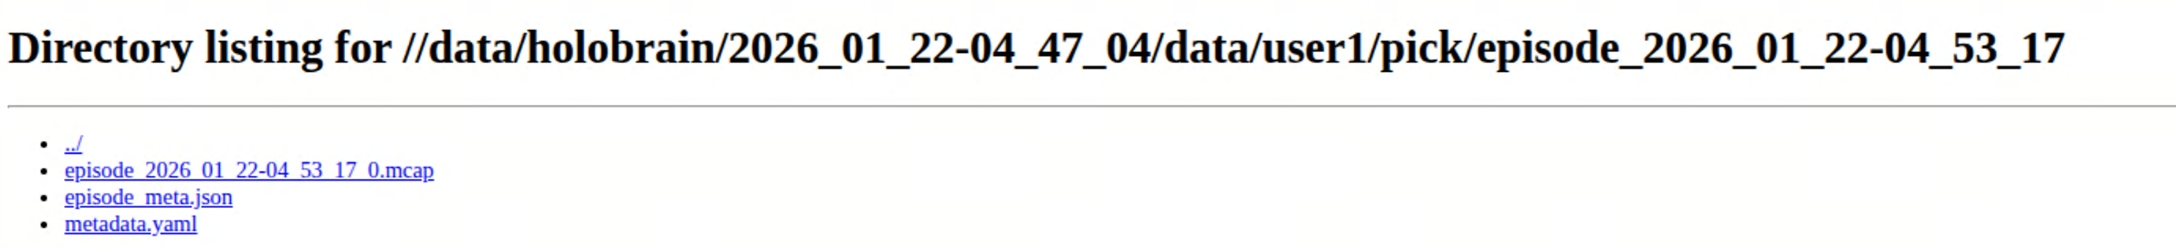
Sample Directory Tree
Extensible Metadata: The system offers extensible meta-key configurations to accommodate project-specific metadata requirements.
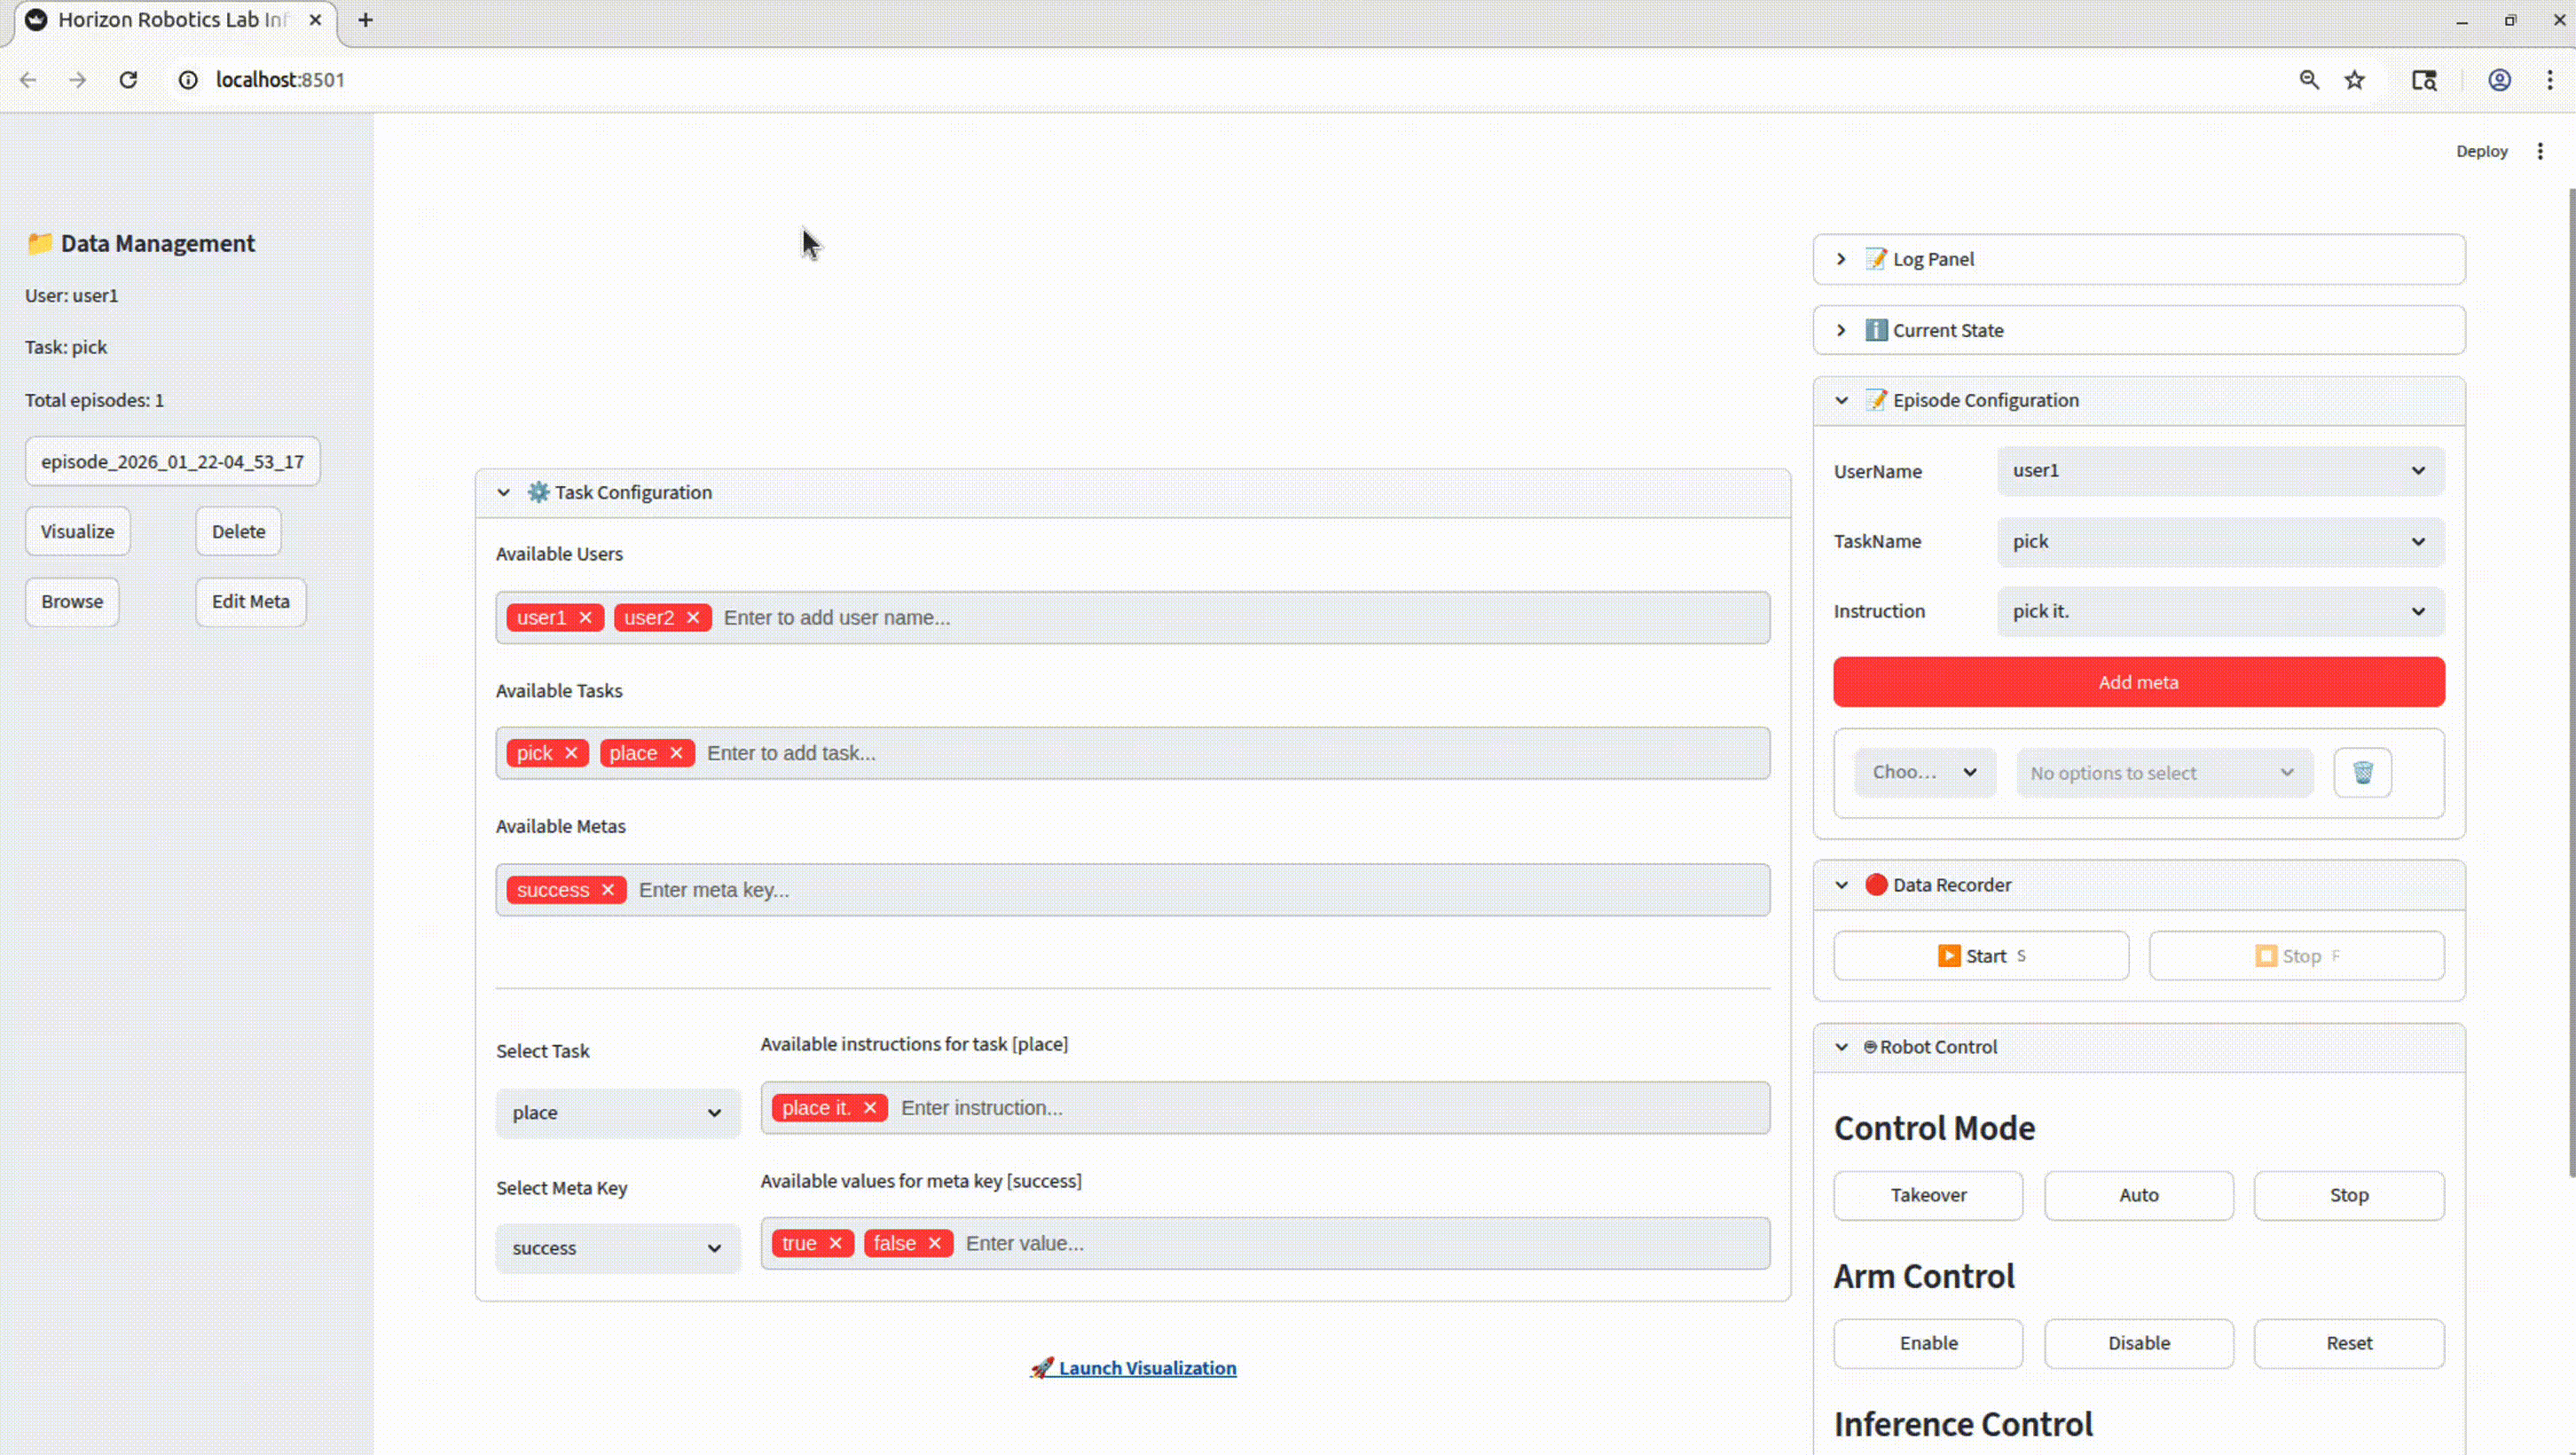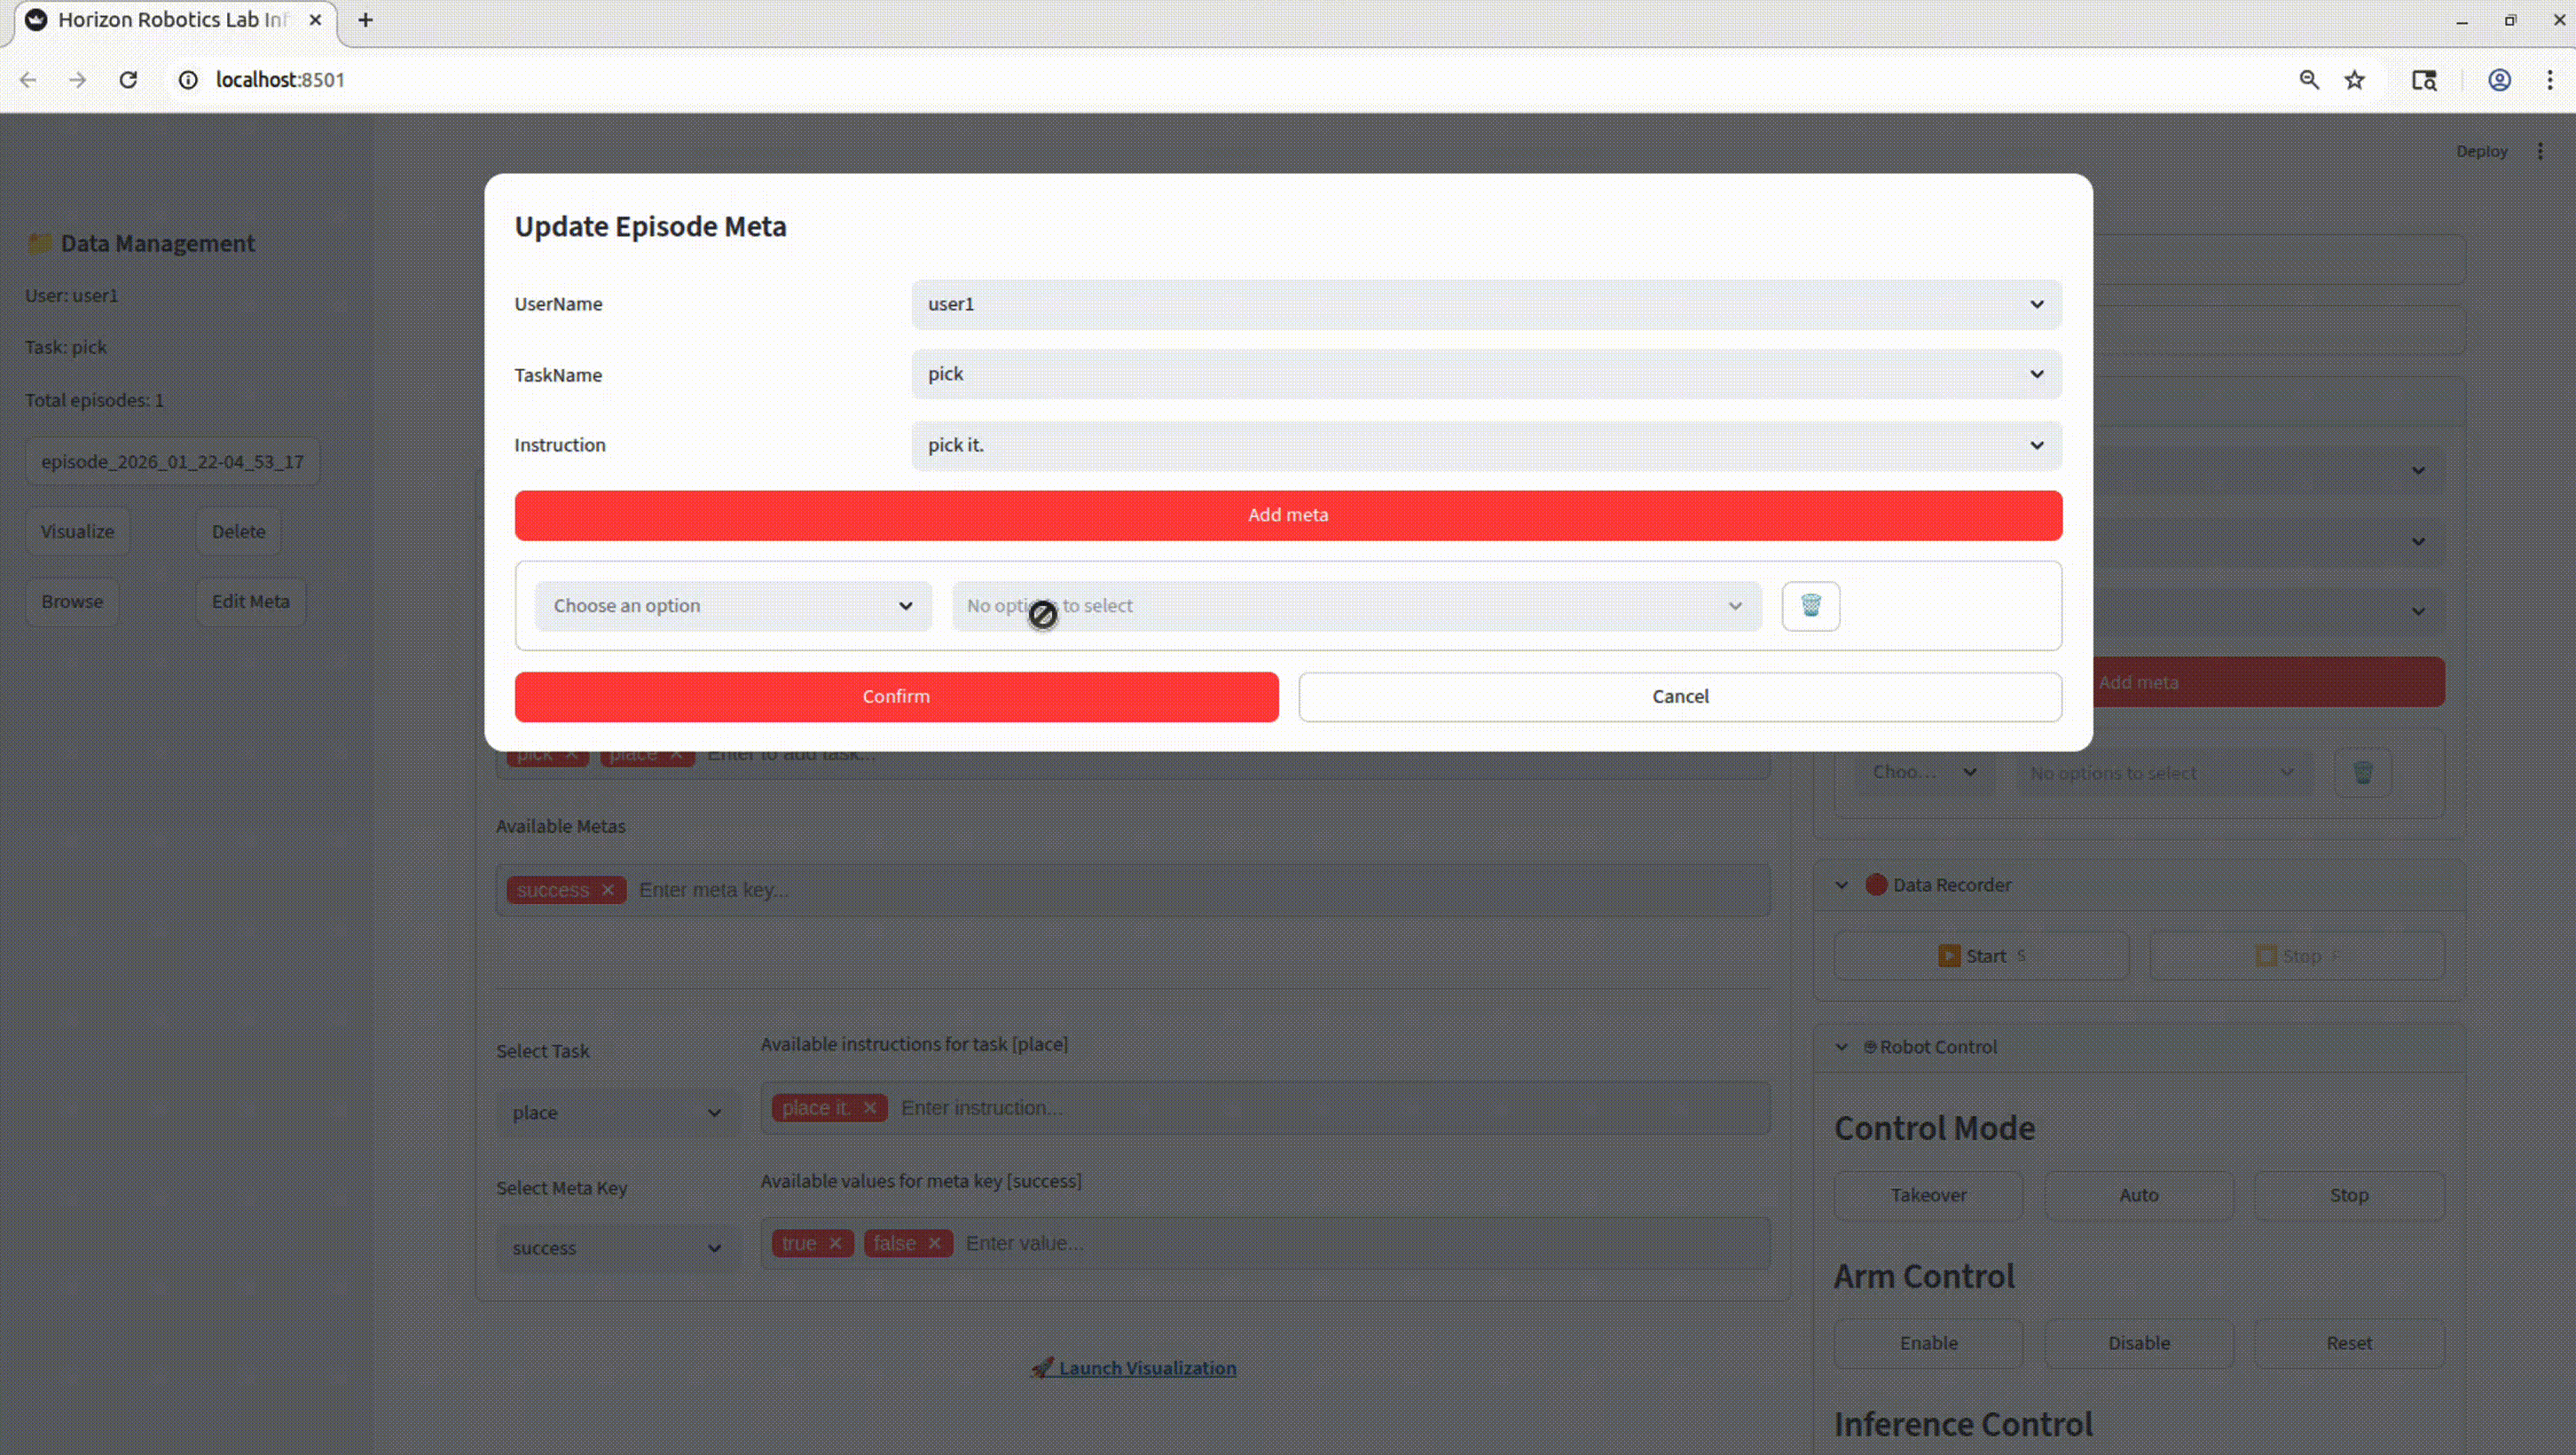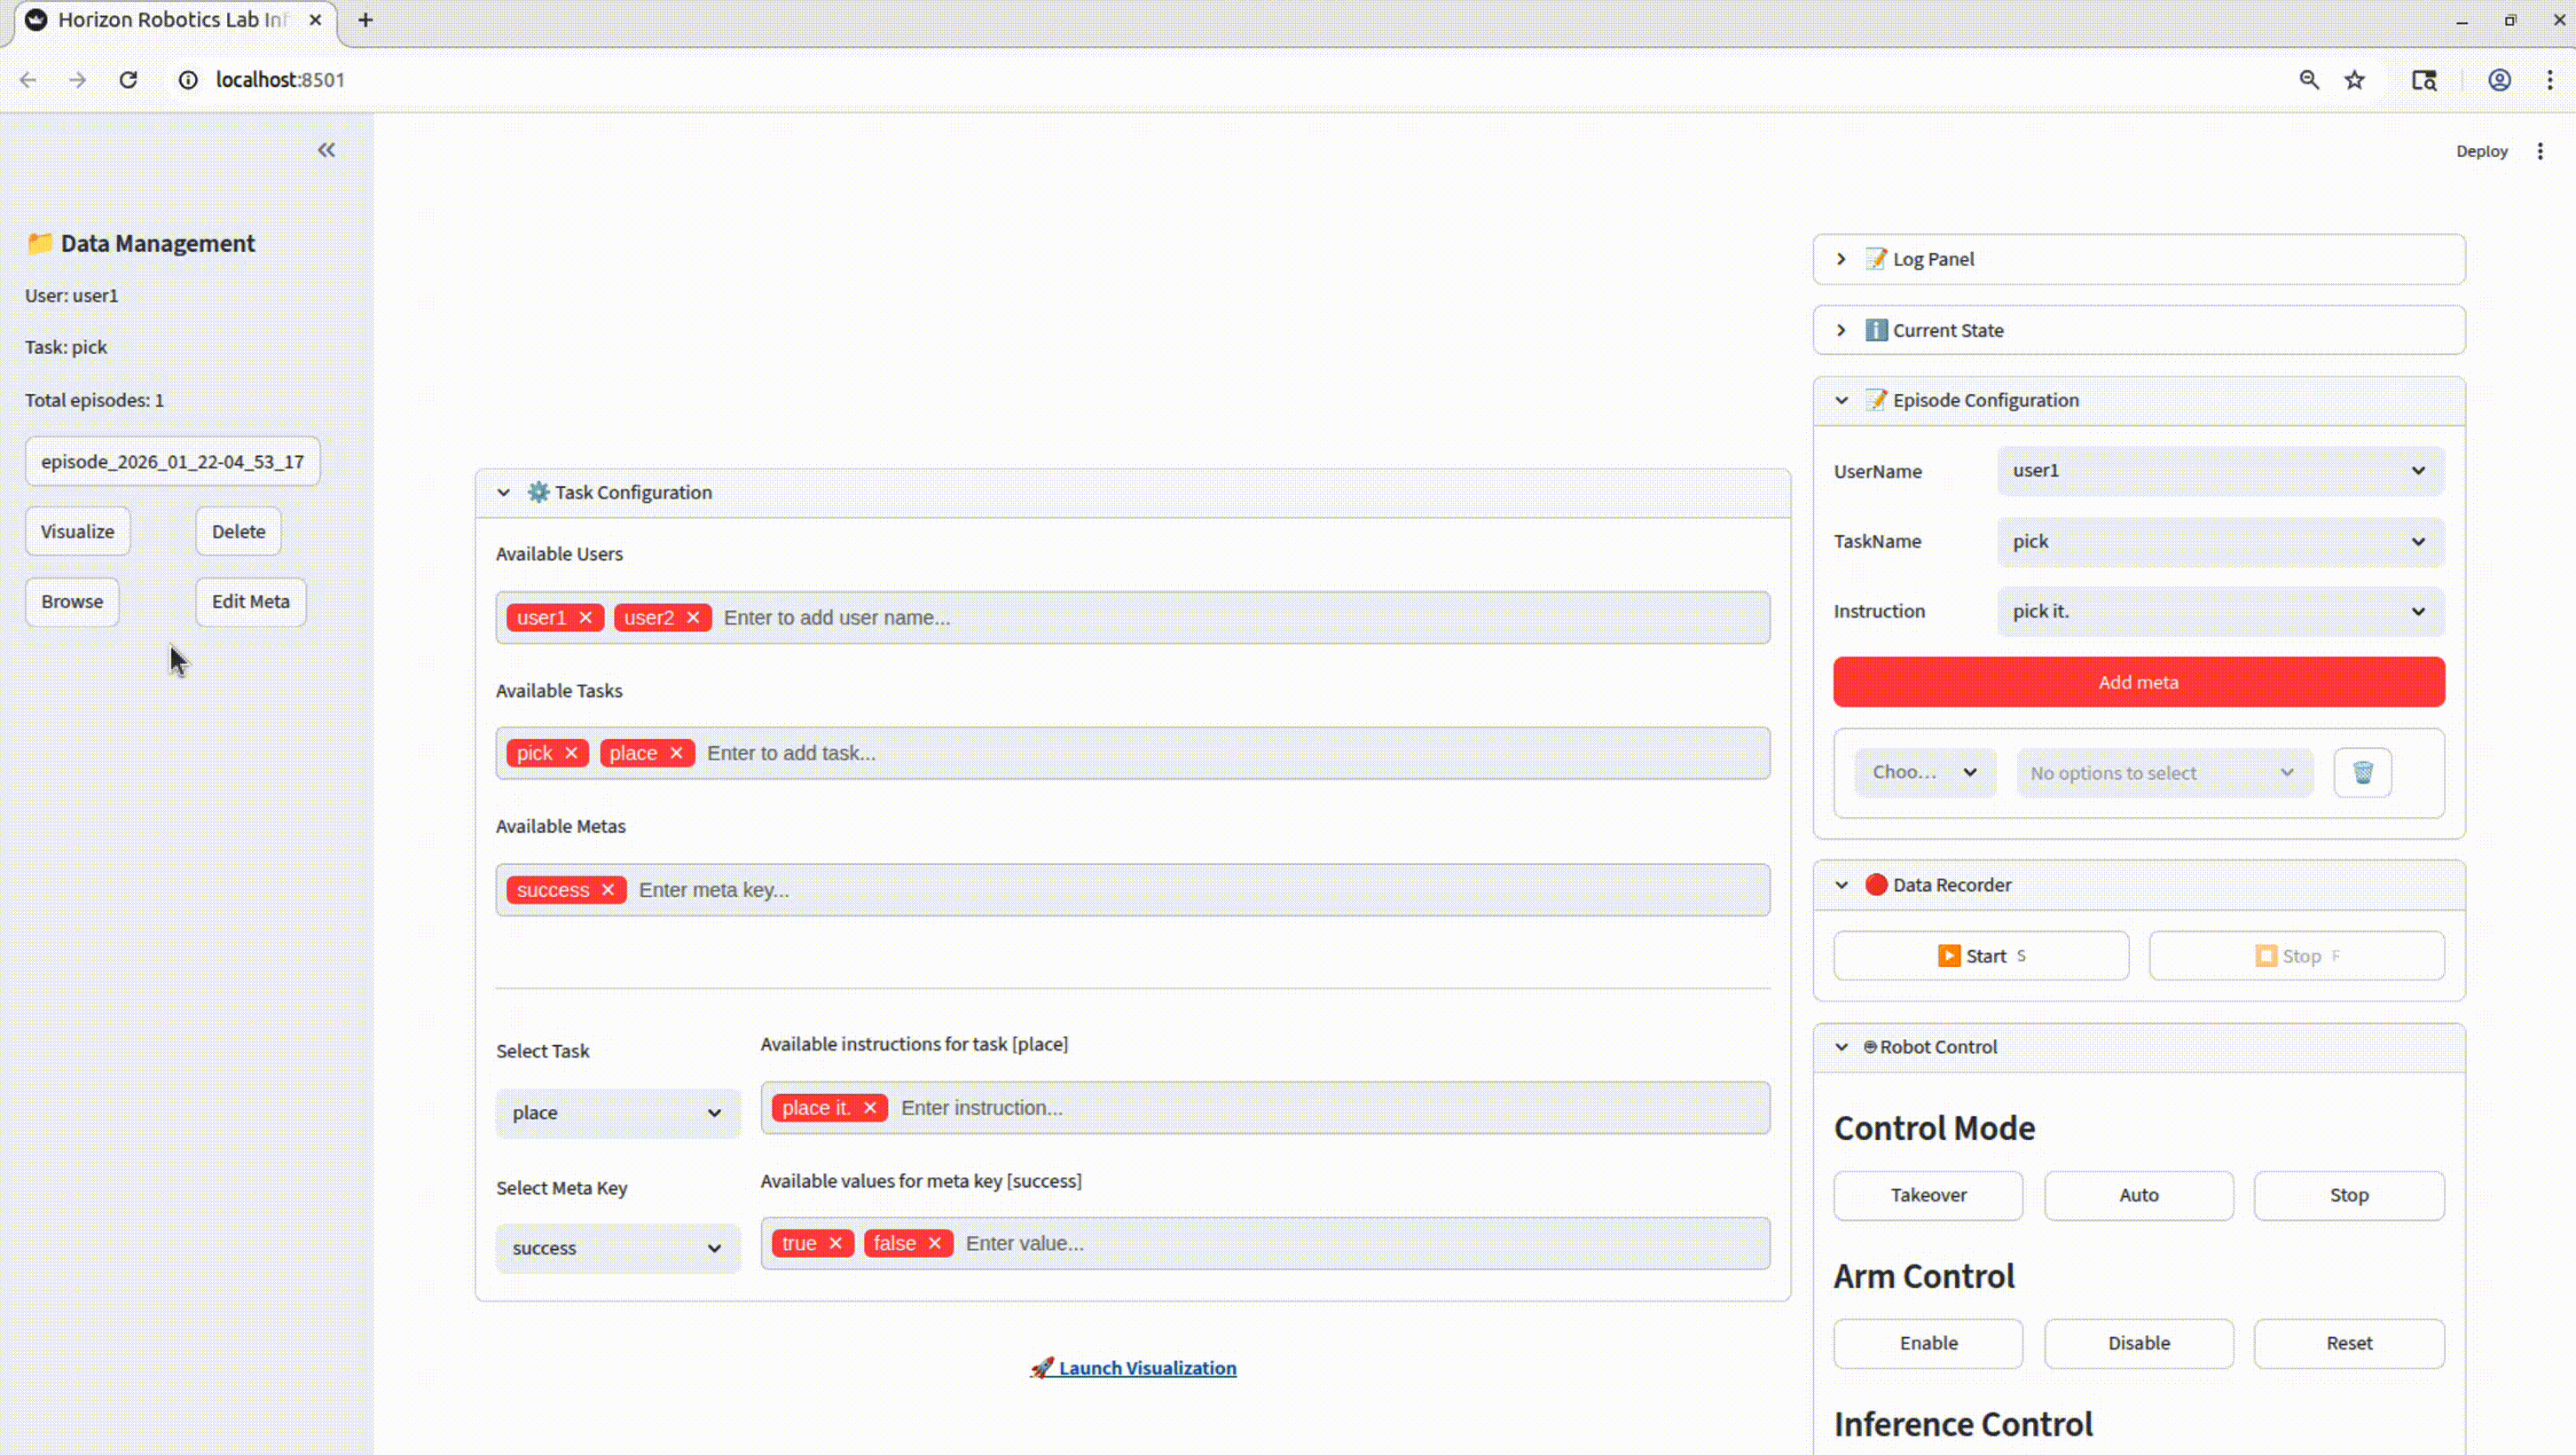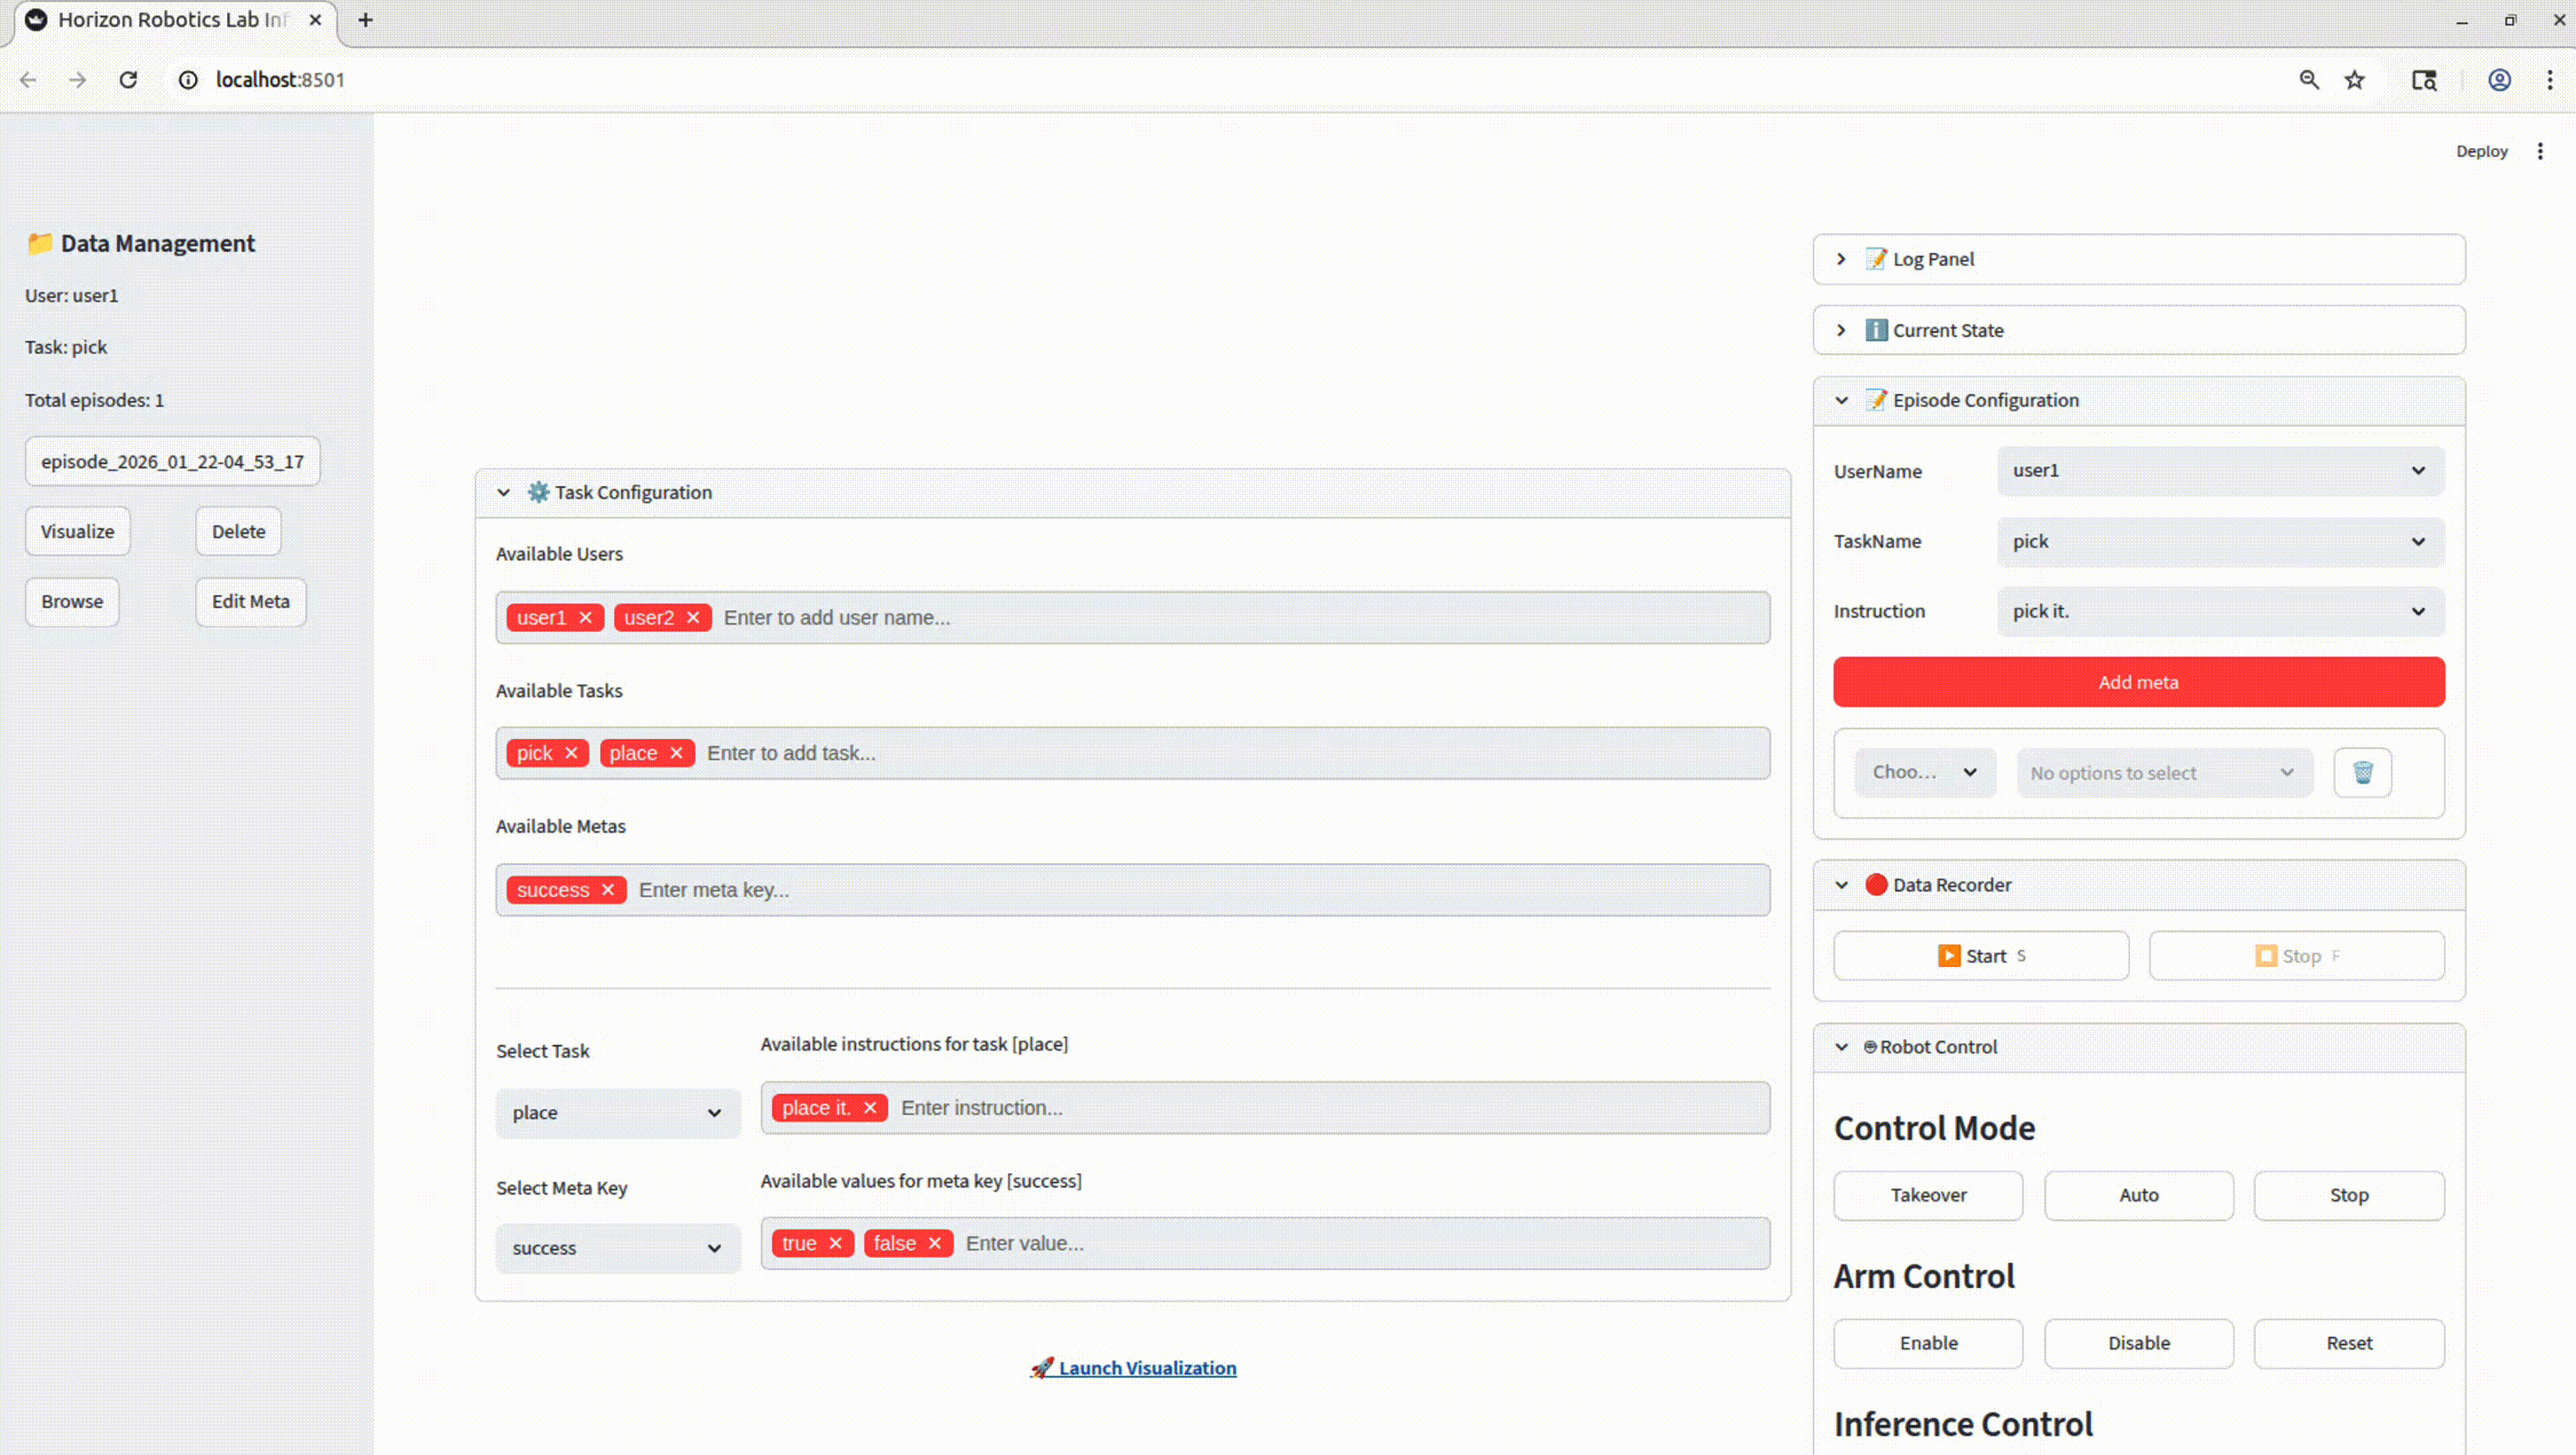
Sample Metadata Configuration
2. Data Quality & Transmission Optimization
Bandwidth Optimization: To mitigate bottlenecks in multi-sensor configurations, the system incorporates real-time, on-the-fly image compression and encoding.
Active Diagnostics: A dedicated diagnostic suite monitors frame rates in real-time. It provides instant alerts for data anomalies, such as camera frame drops or node failures, ensuring the integrity of the collected dataset.
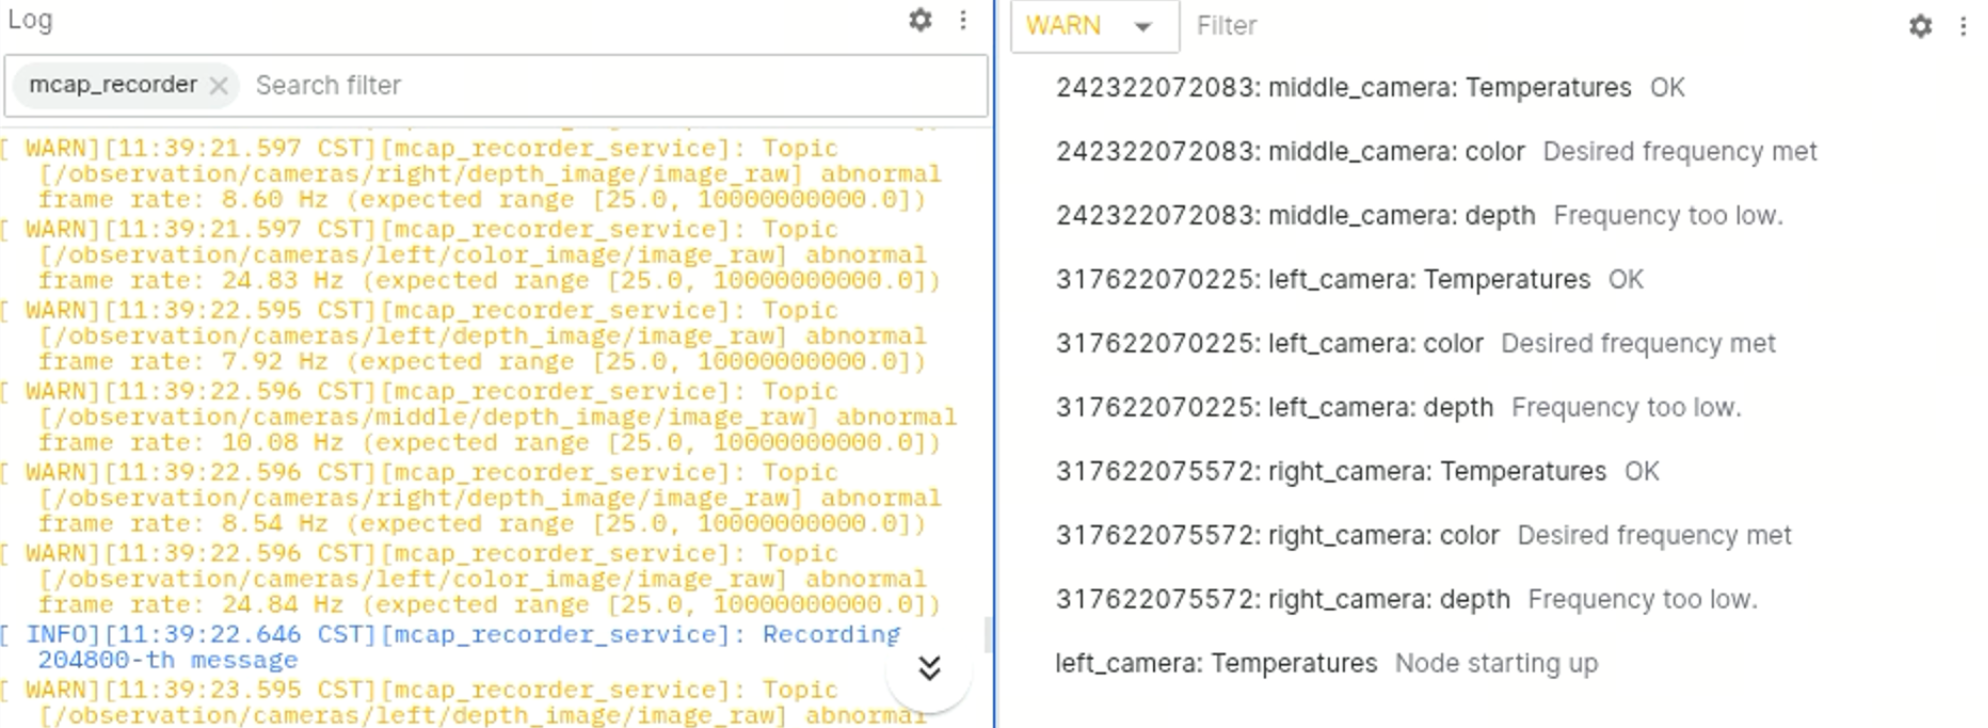
Active Diagnostics
3. Visualization & Playback Interfaces
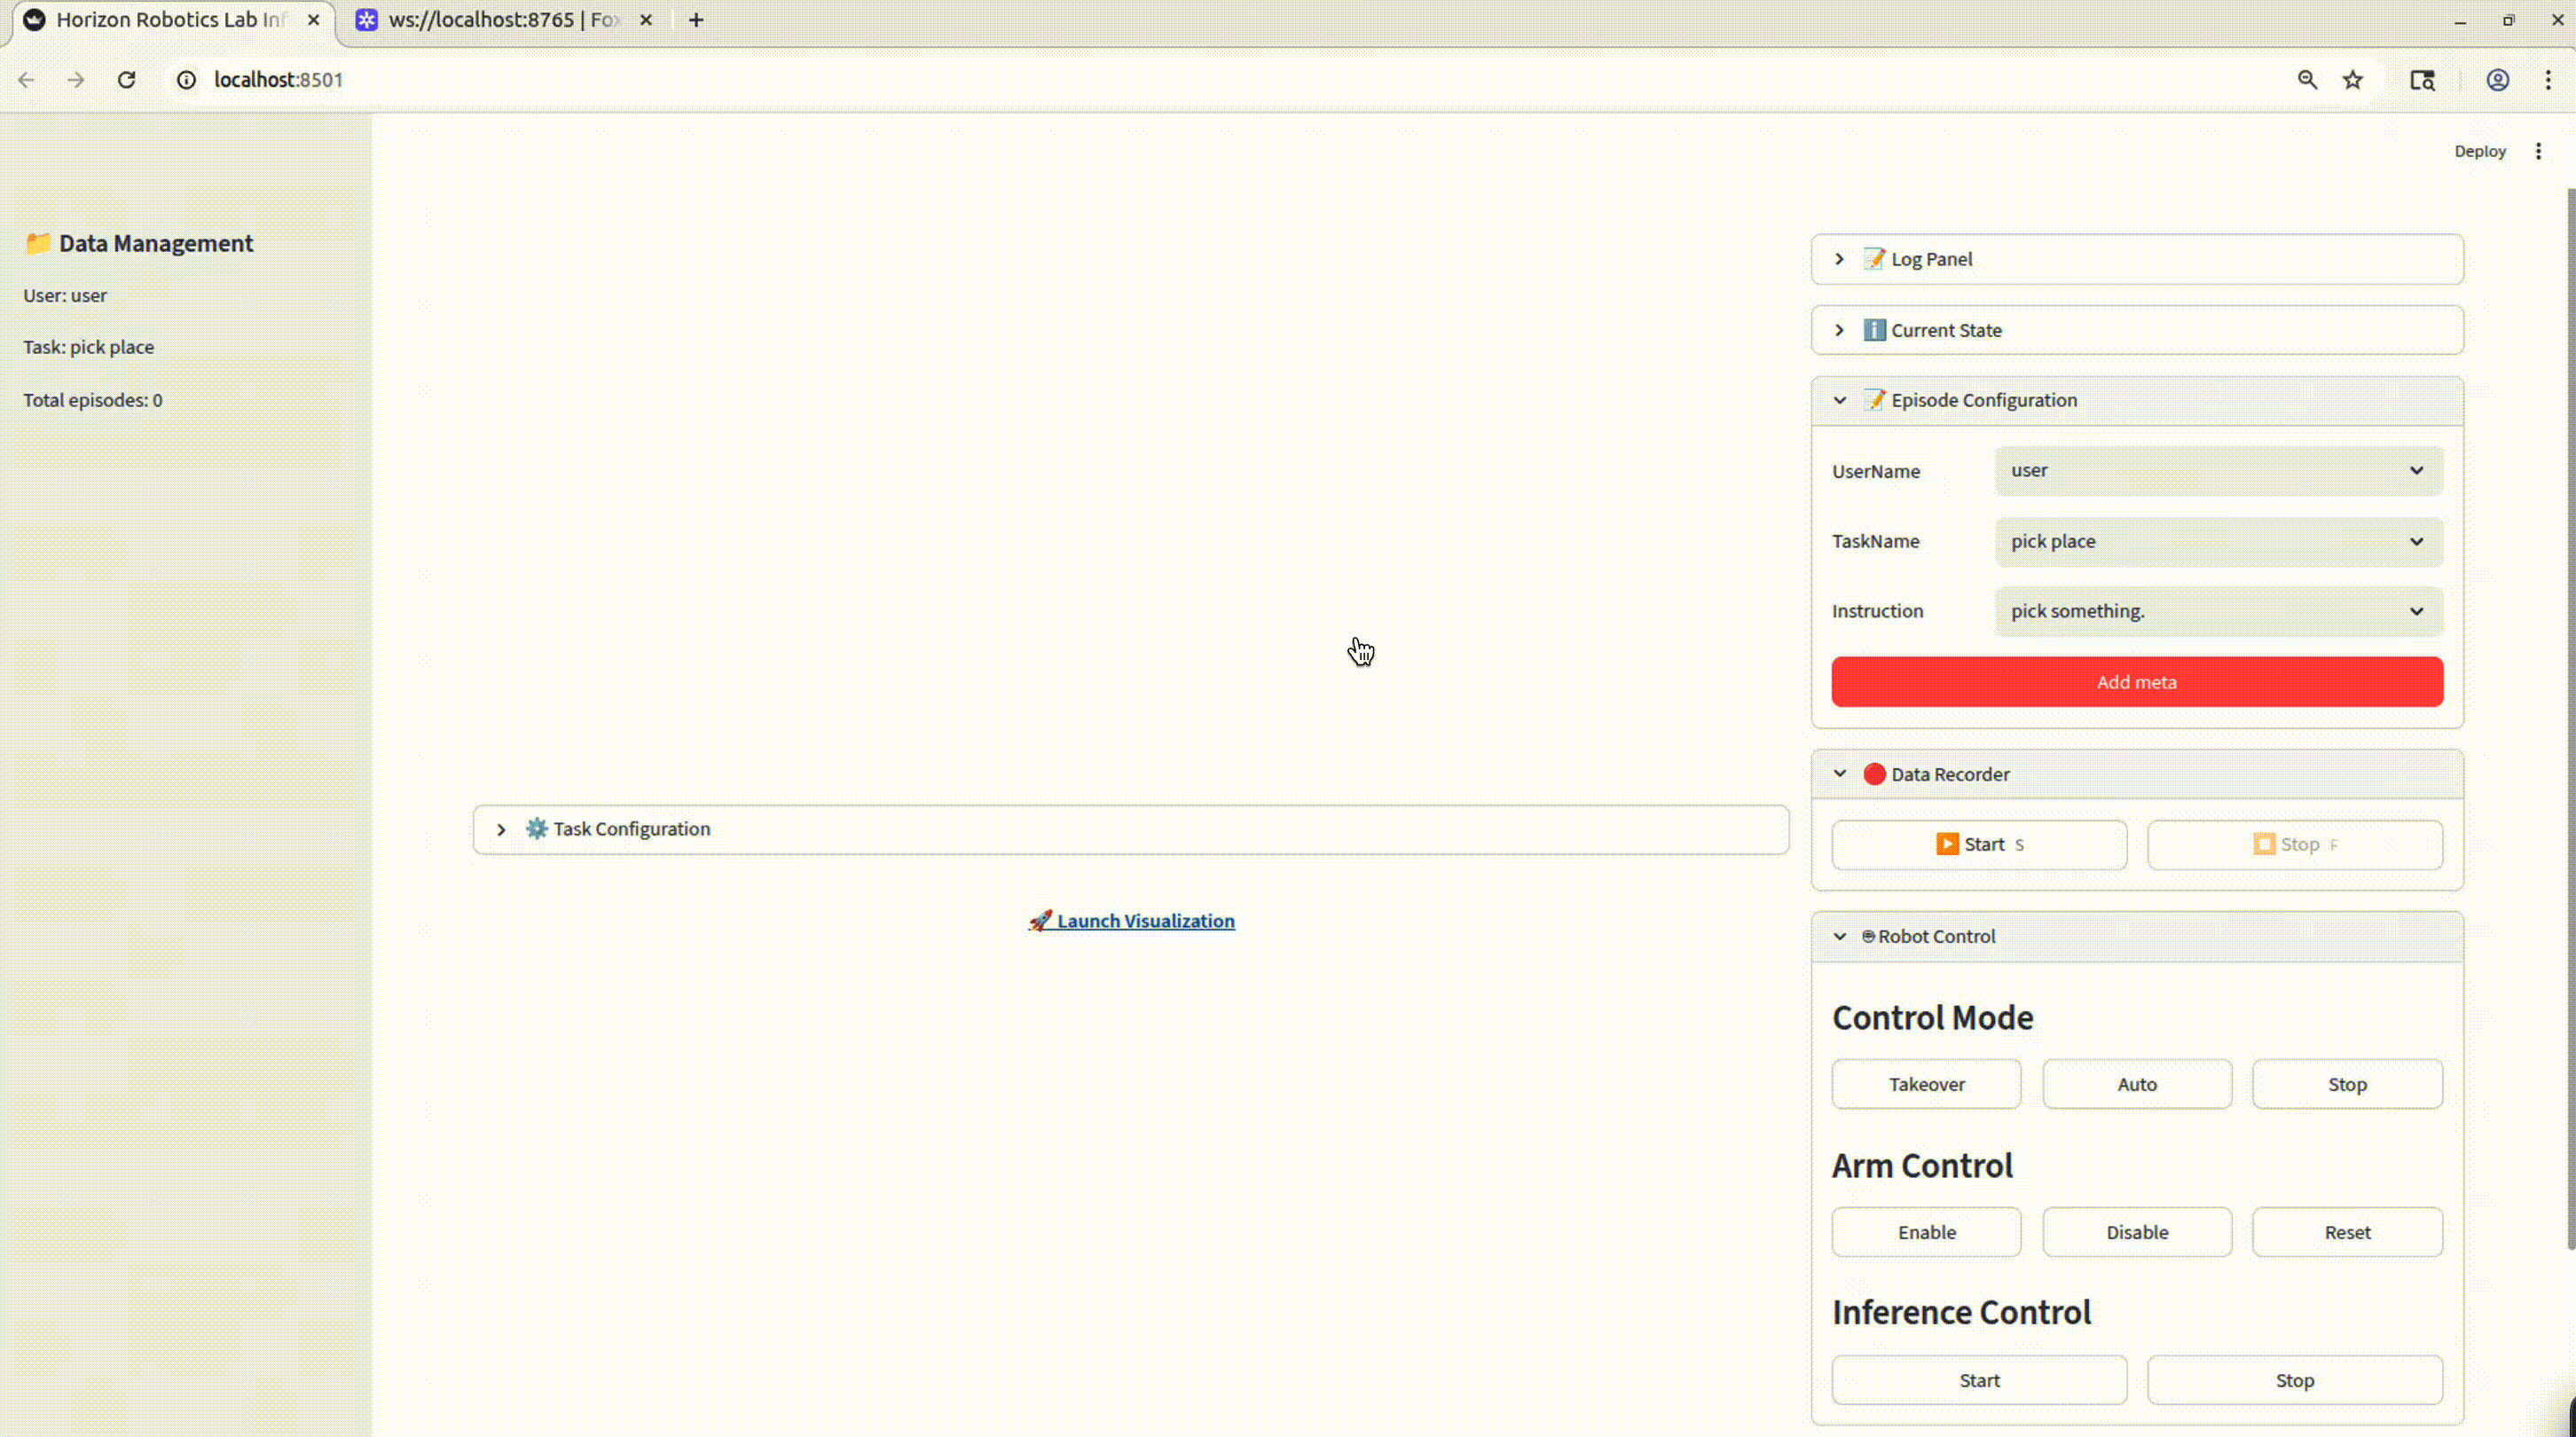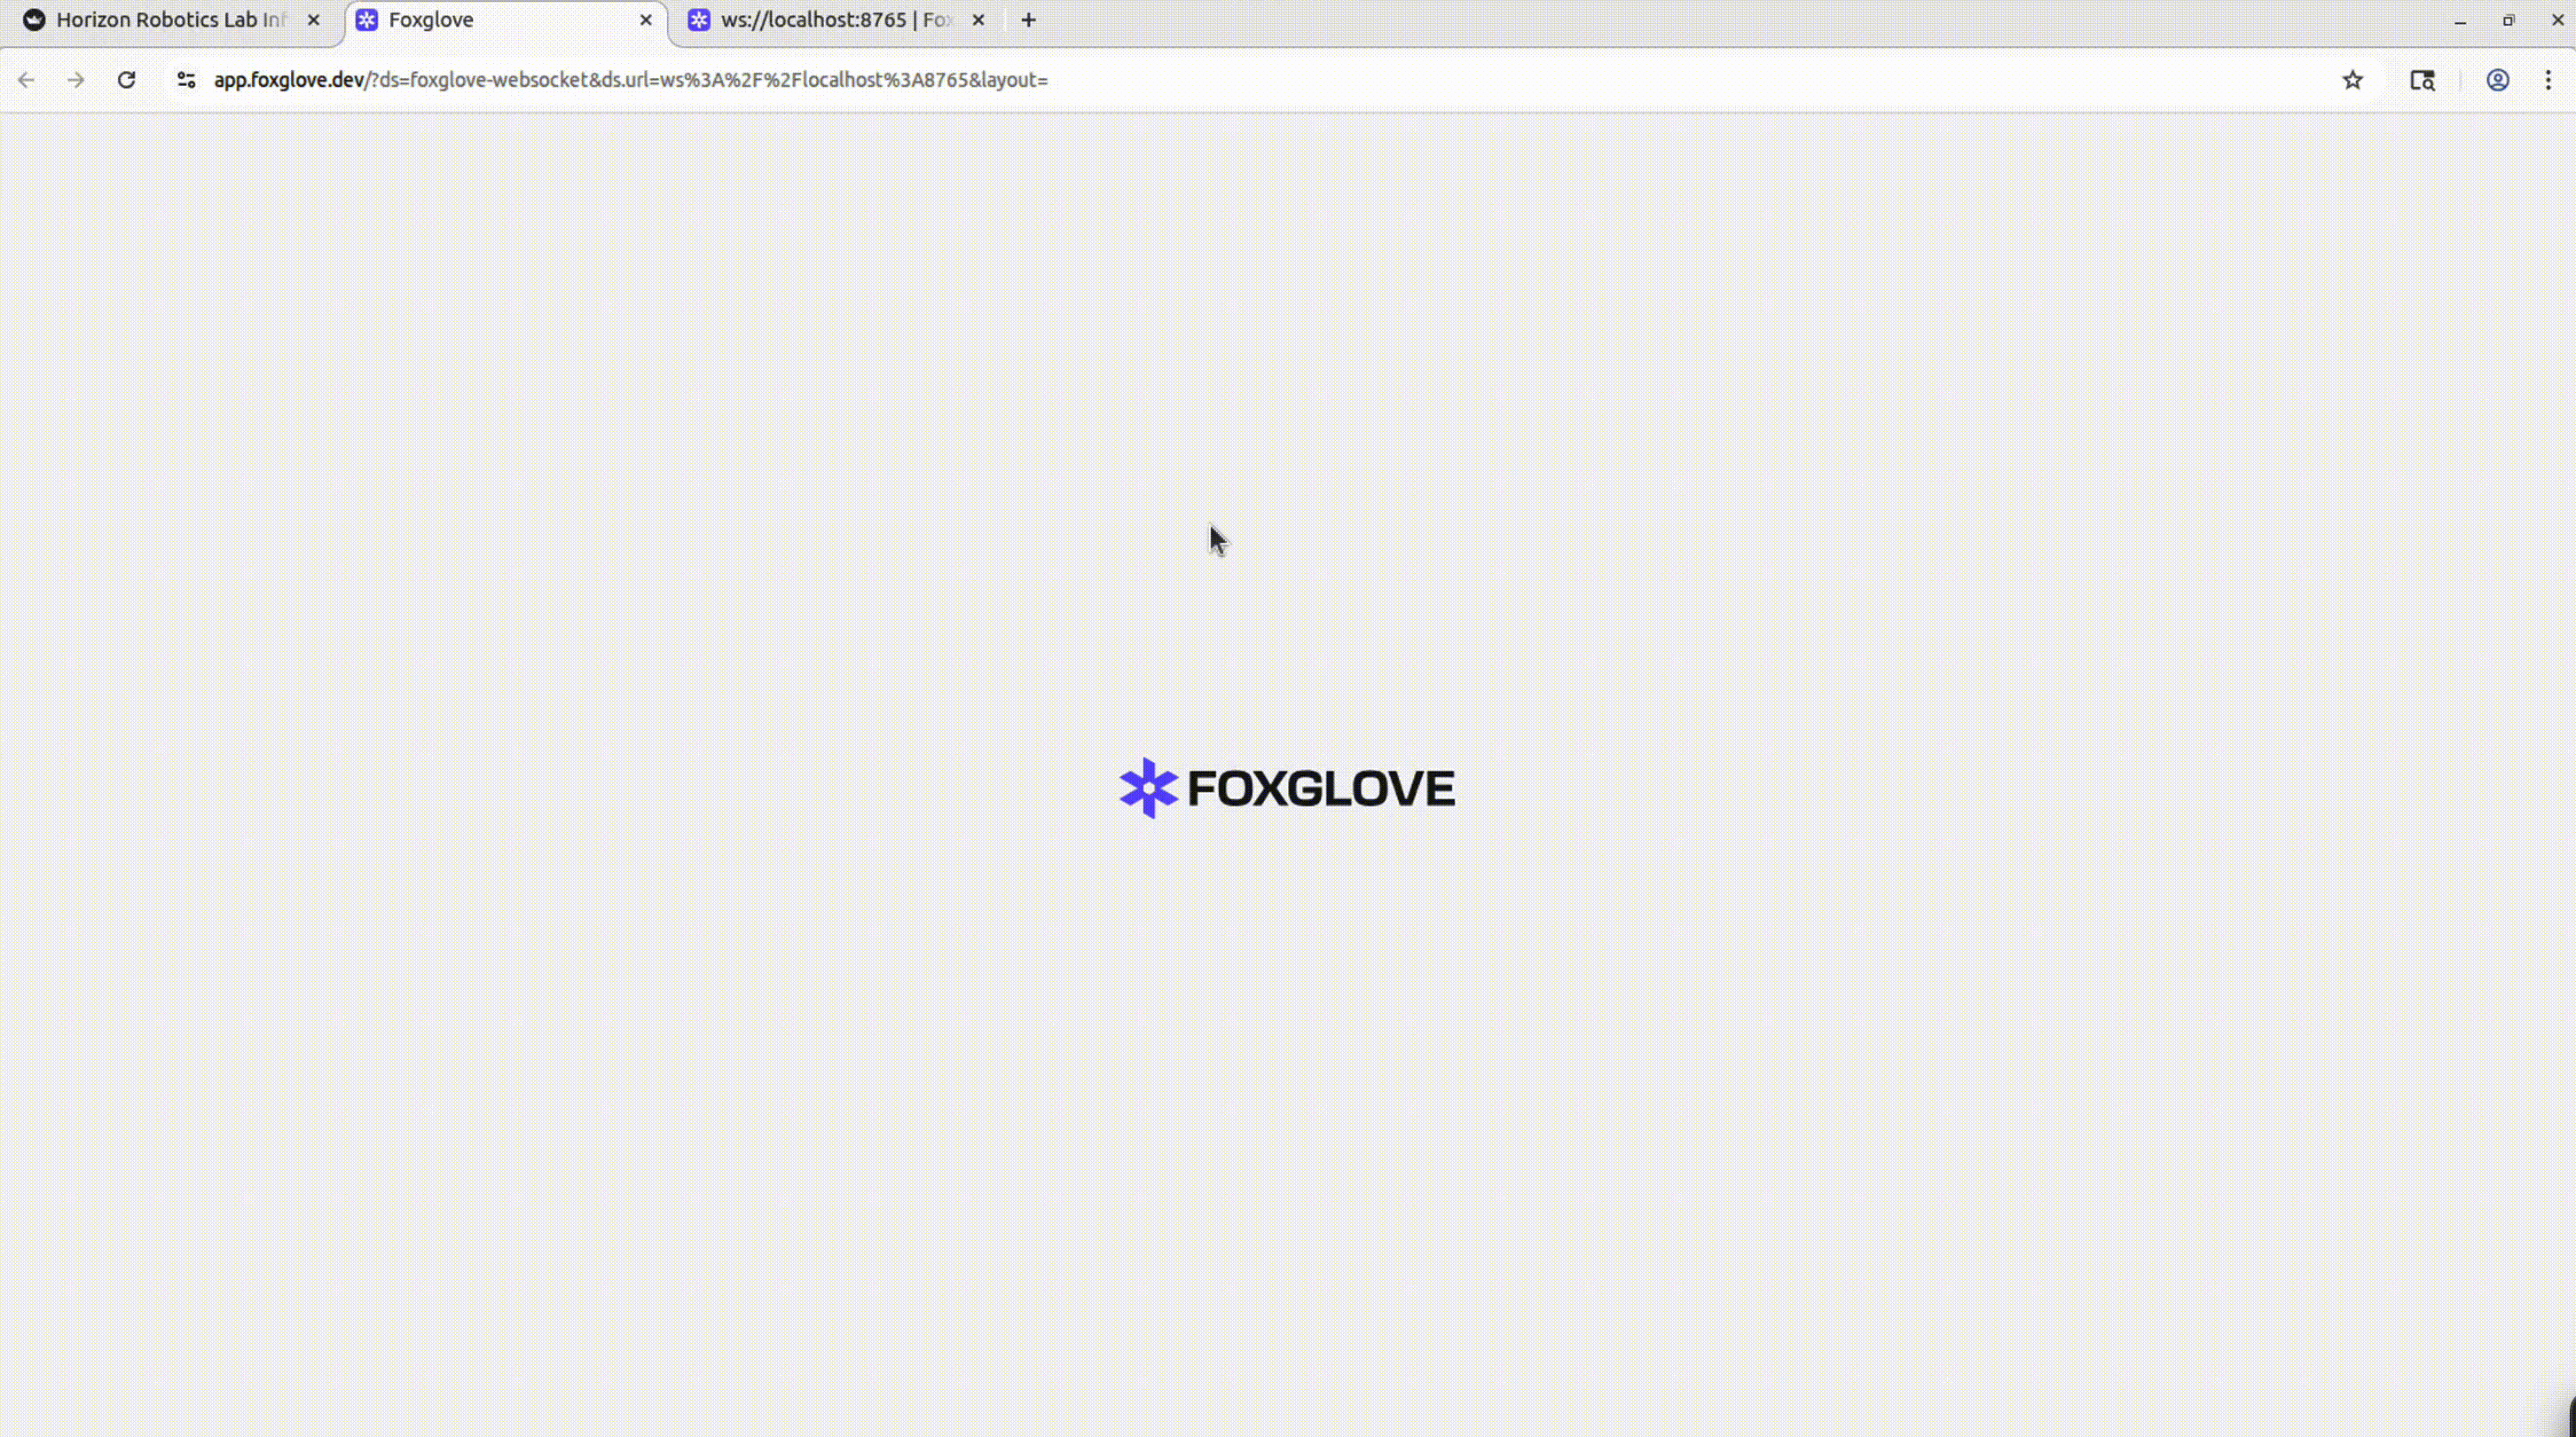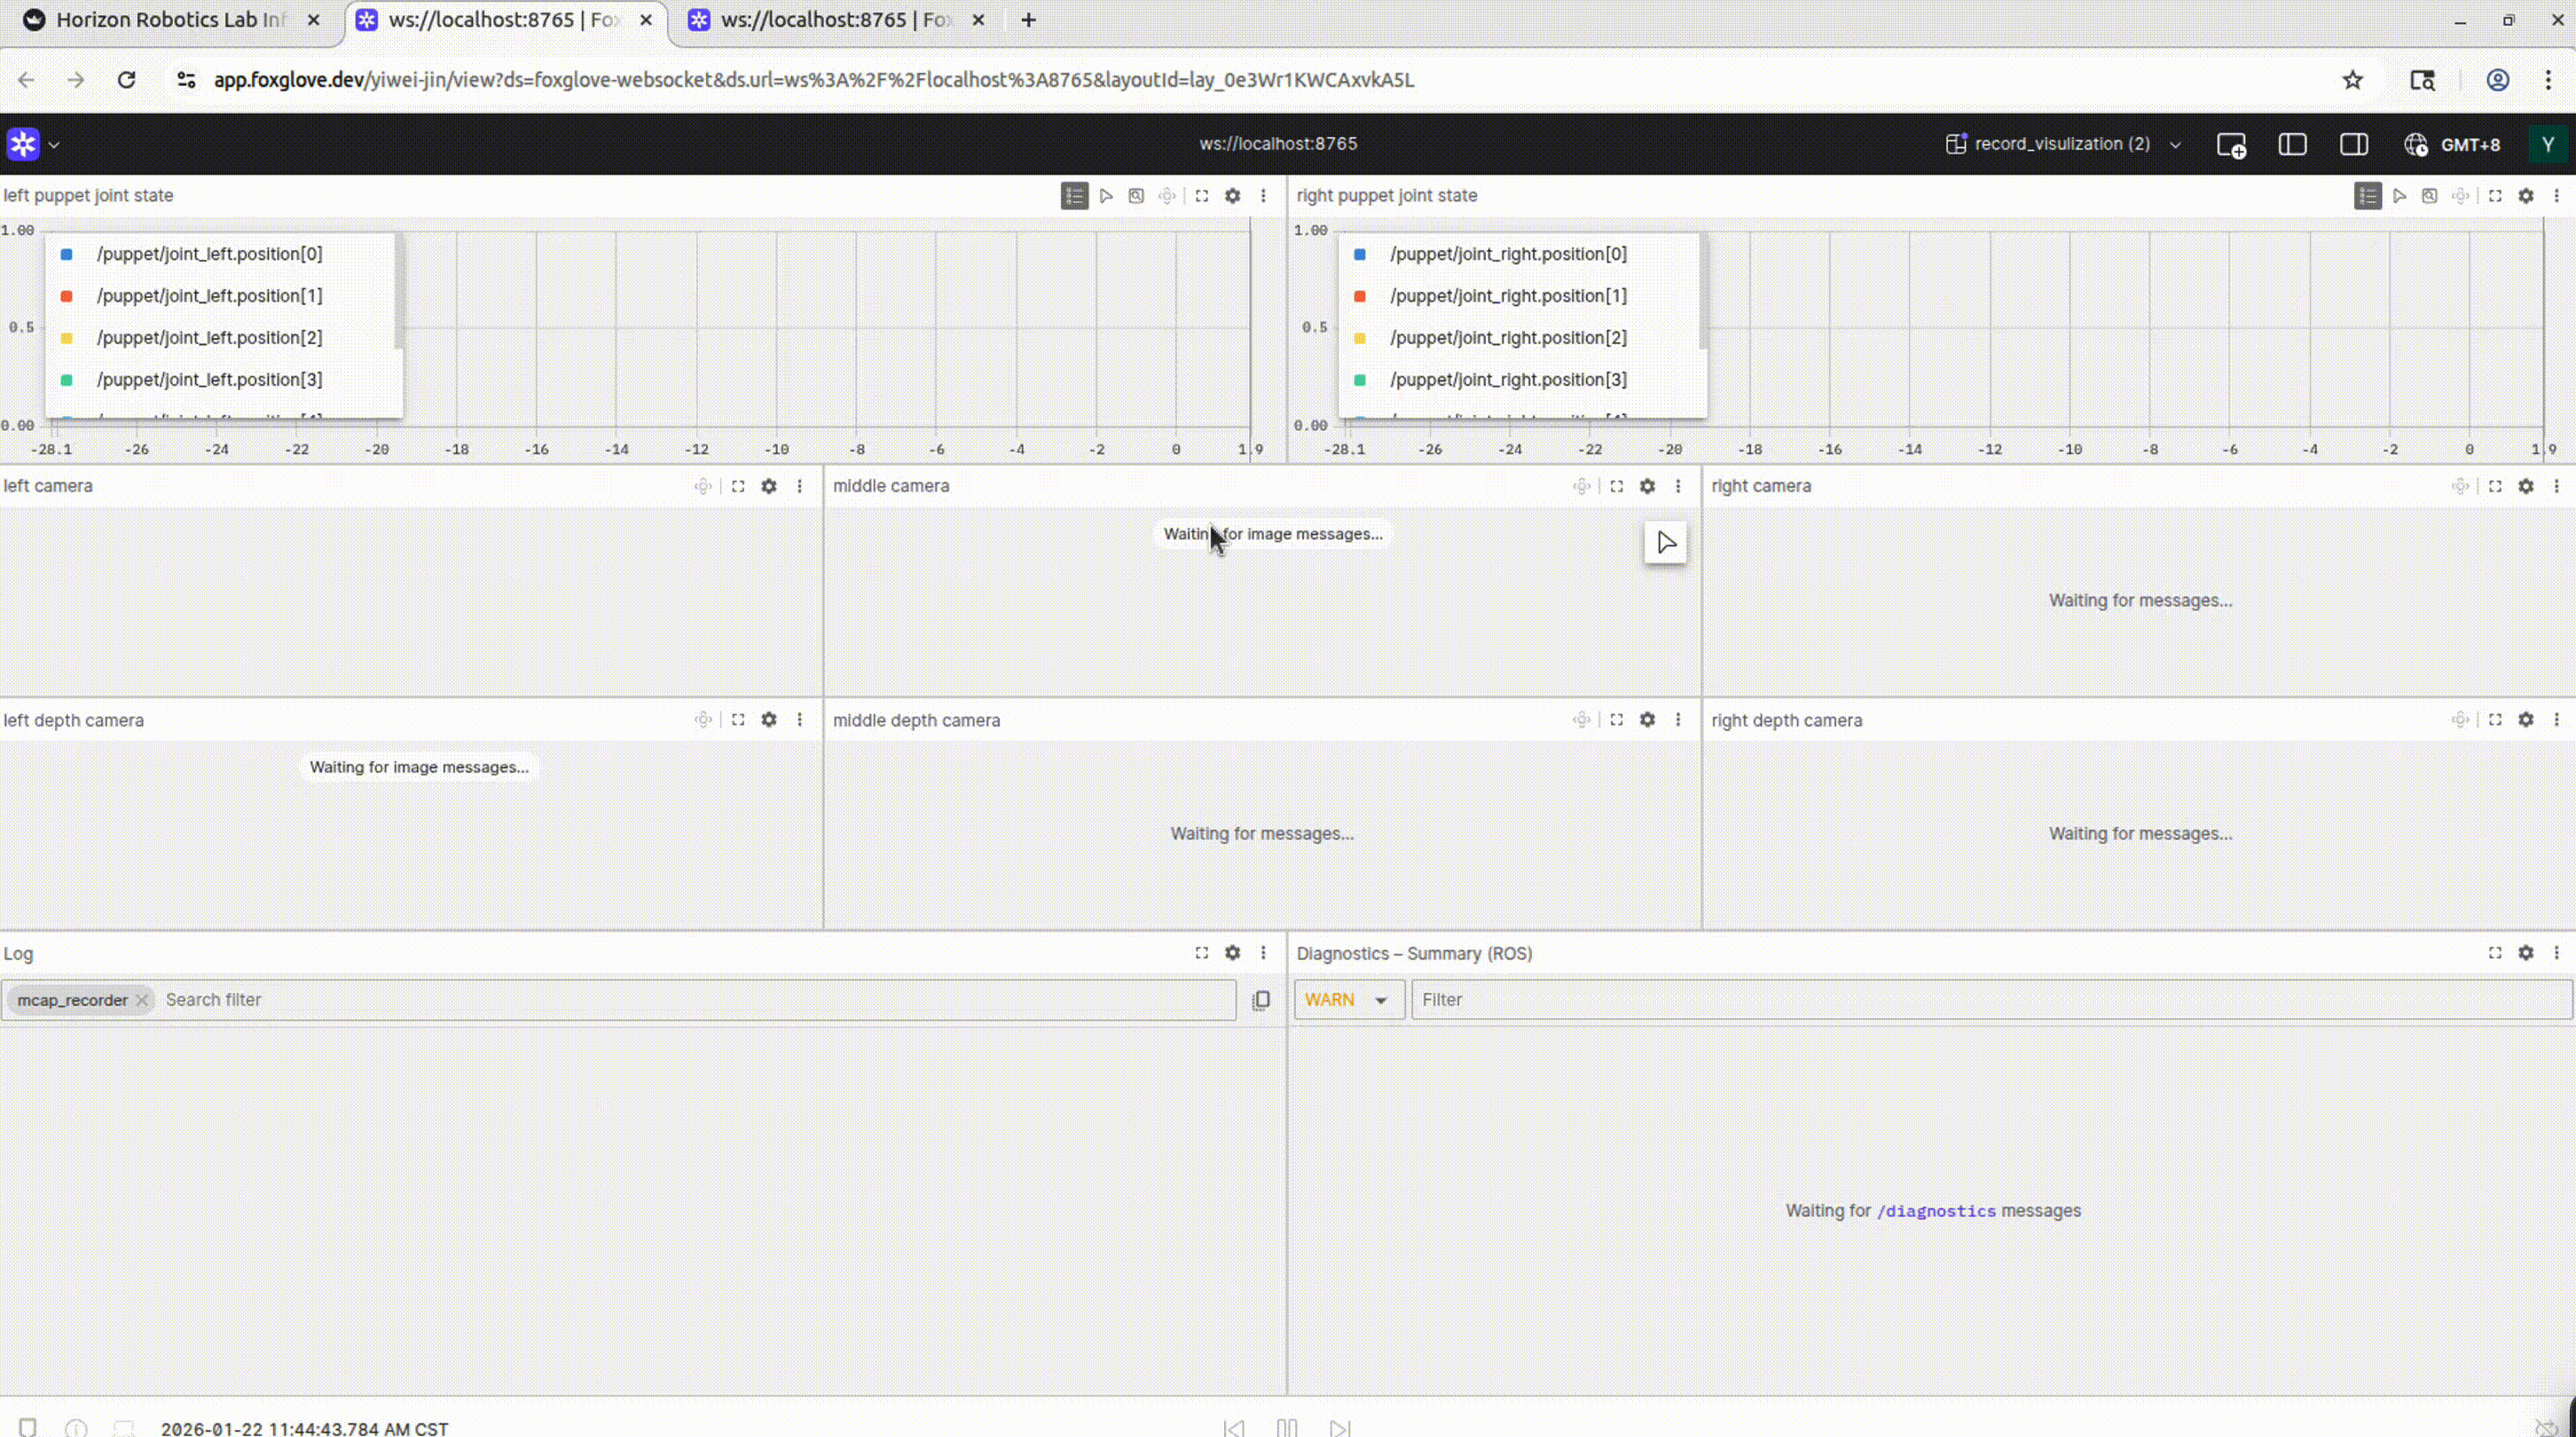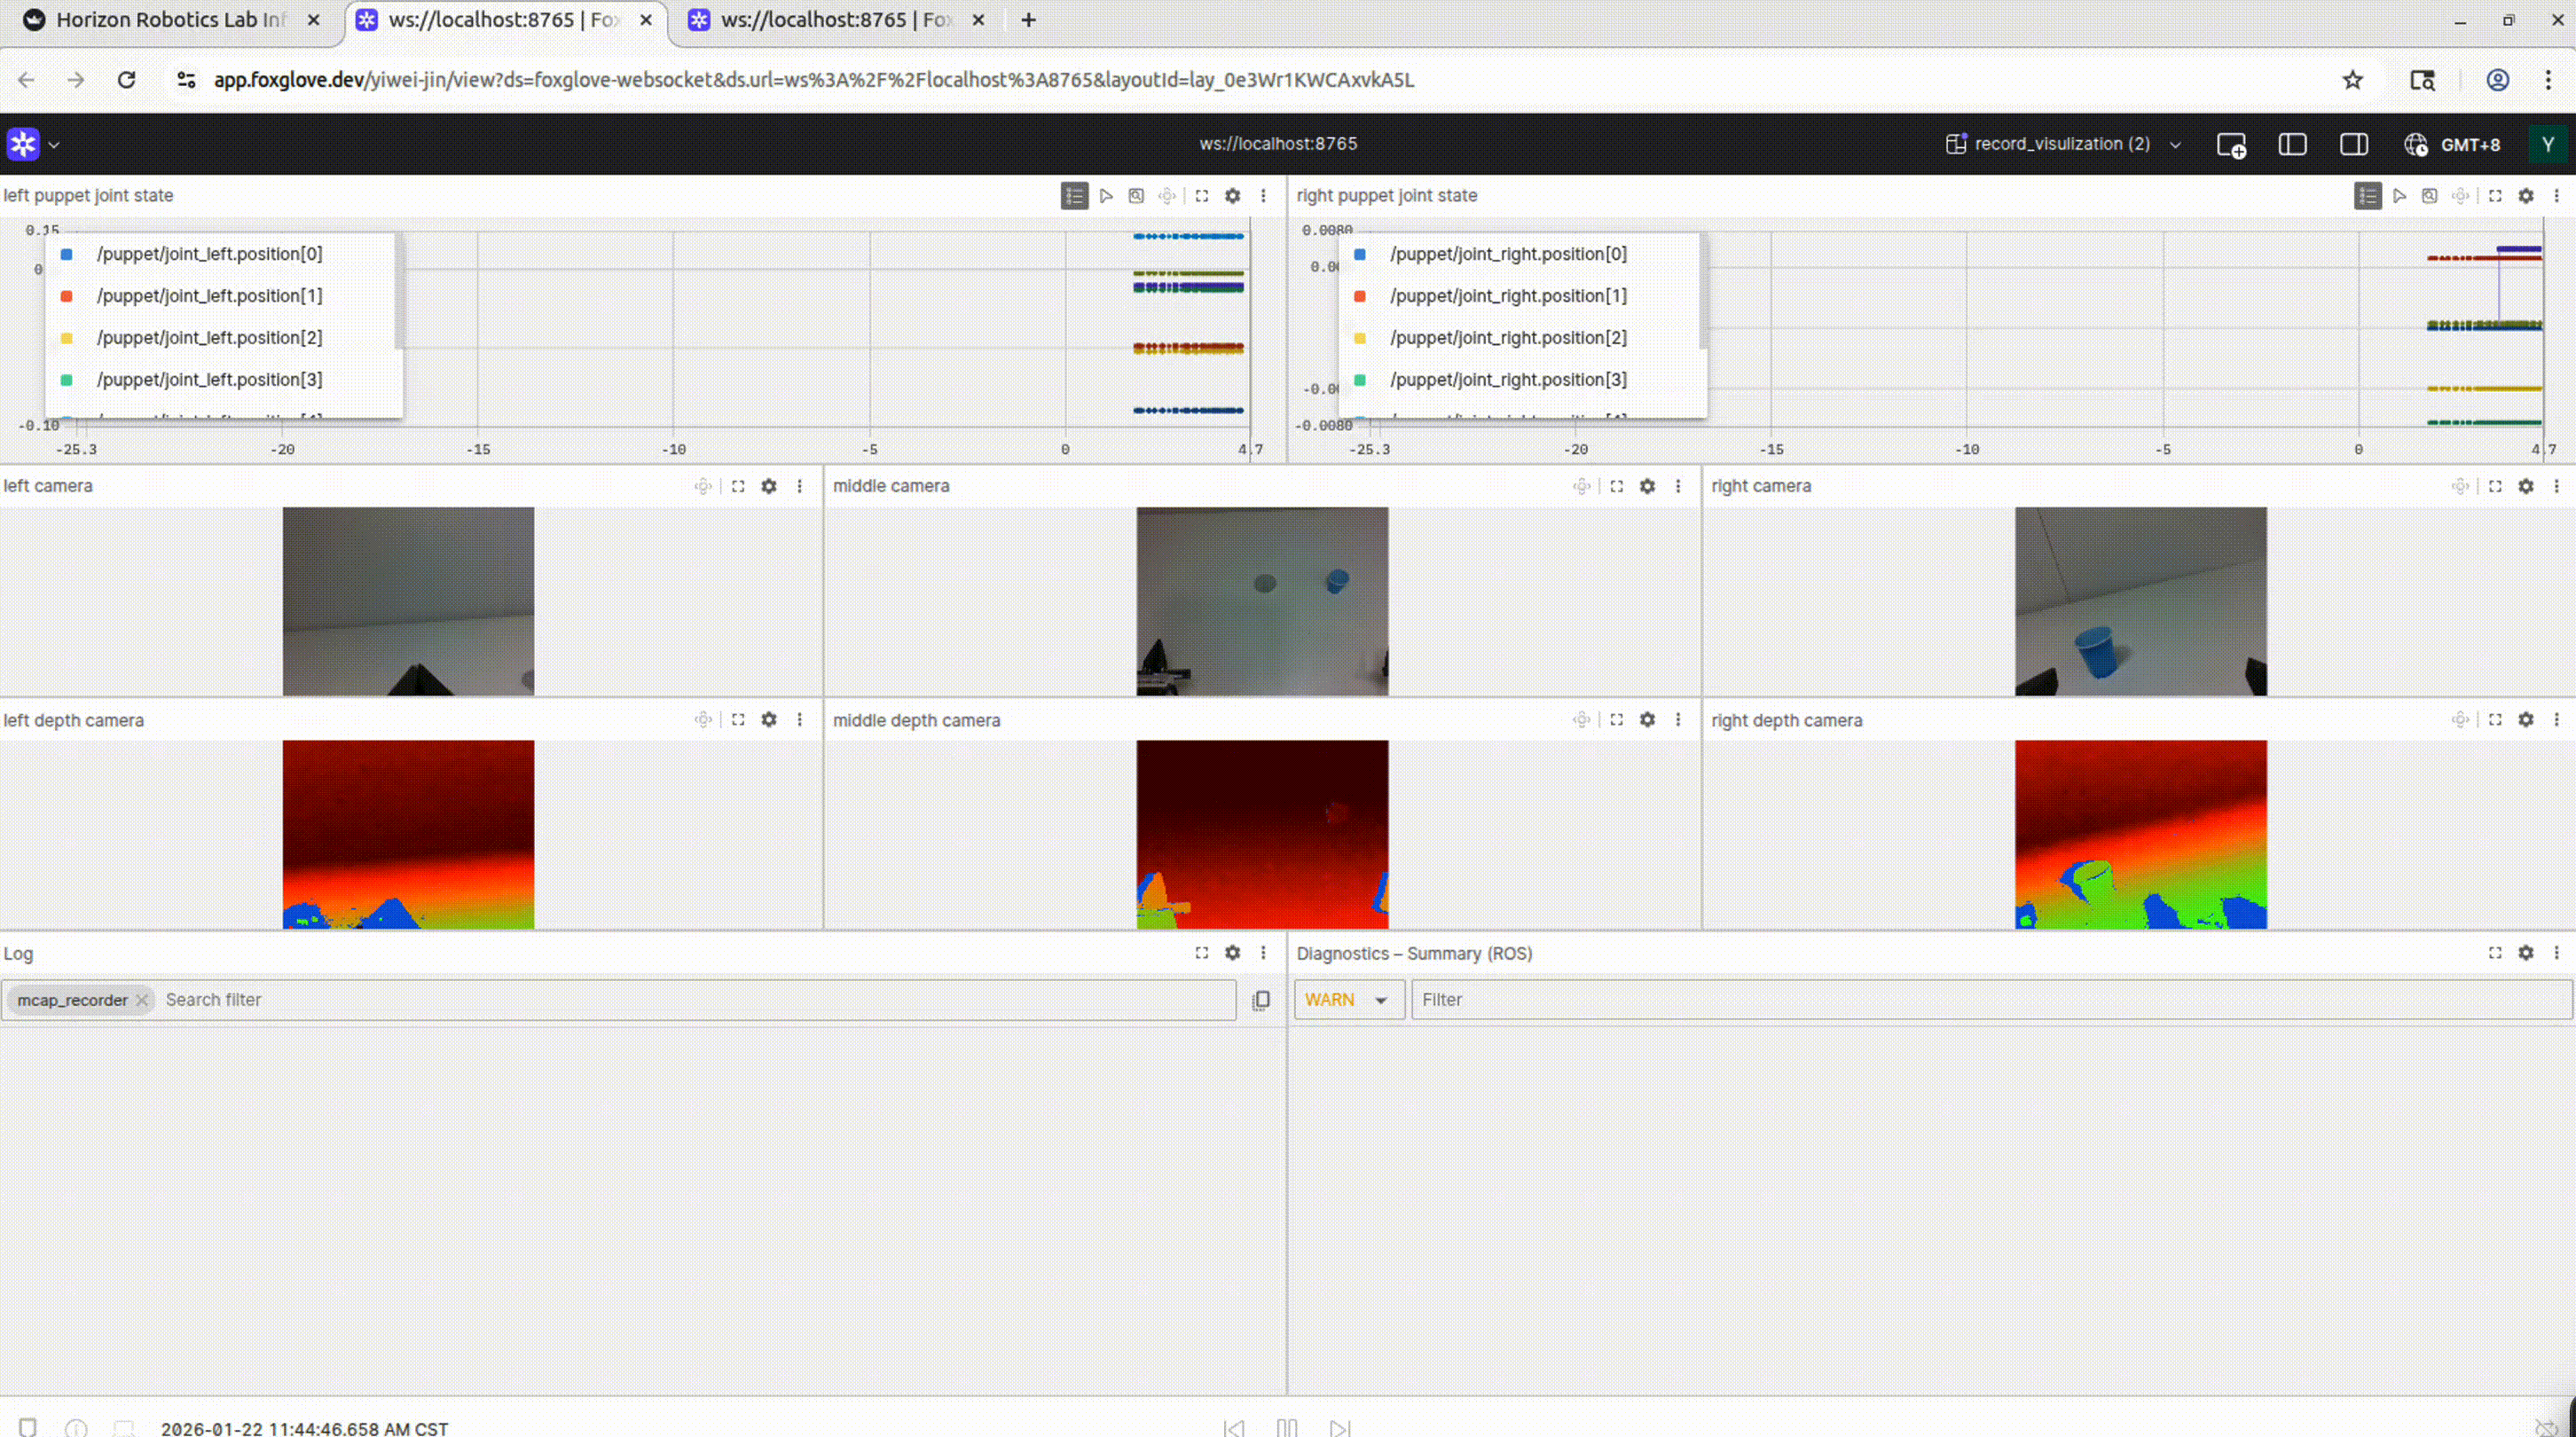
Real-time Visualization: We provide an integrated entrance for real-time data streaming and visualization through Foxglove, enabling live monitoring of robot states and sensor feeds.
Seamless Playback: A lightweight
file_serveris integrated into the pipeline, supporting the immediate playback and review of recorded sequences for rapid data verification.