Application
RoboOrchardApp is a lightweight application designed as the primary interface for real-robot functionalities within the HoloBrain ecosystem. It contains the following features:
[Handeye Calibration] Robot arm hand-eye calibration.
[Data Collection] Data Collection.
[Inference & Deployment] Deployment of VLA Models.
[Teleoperation] Teleoperation control of robot arms.
It also includes a Foxglove visualization interface for real-time data display and logging.
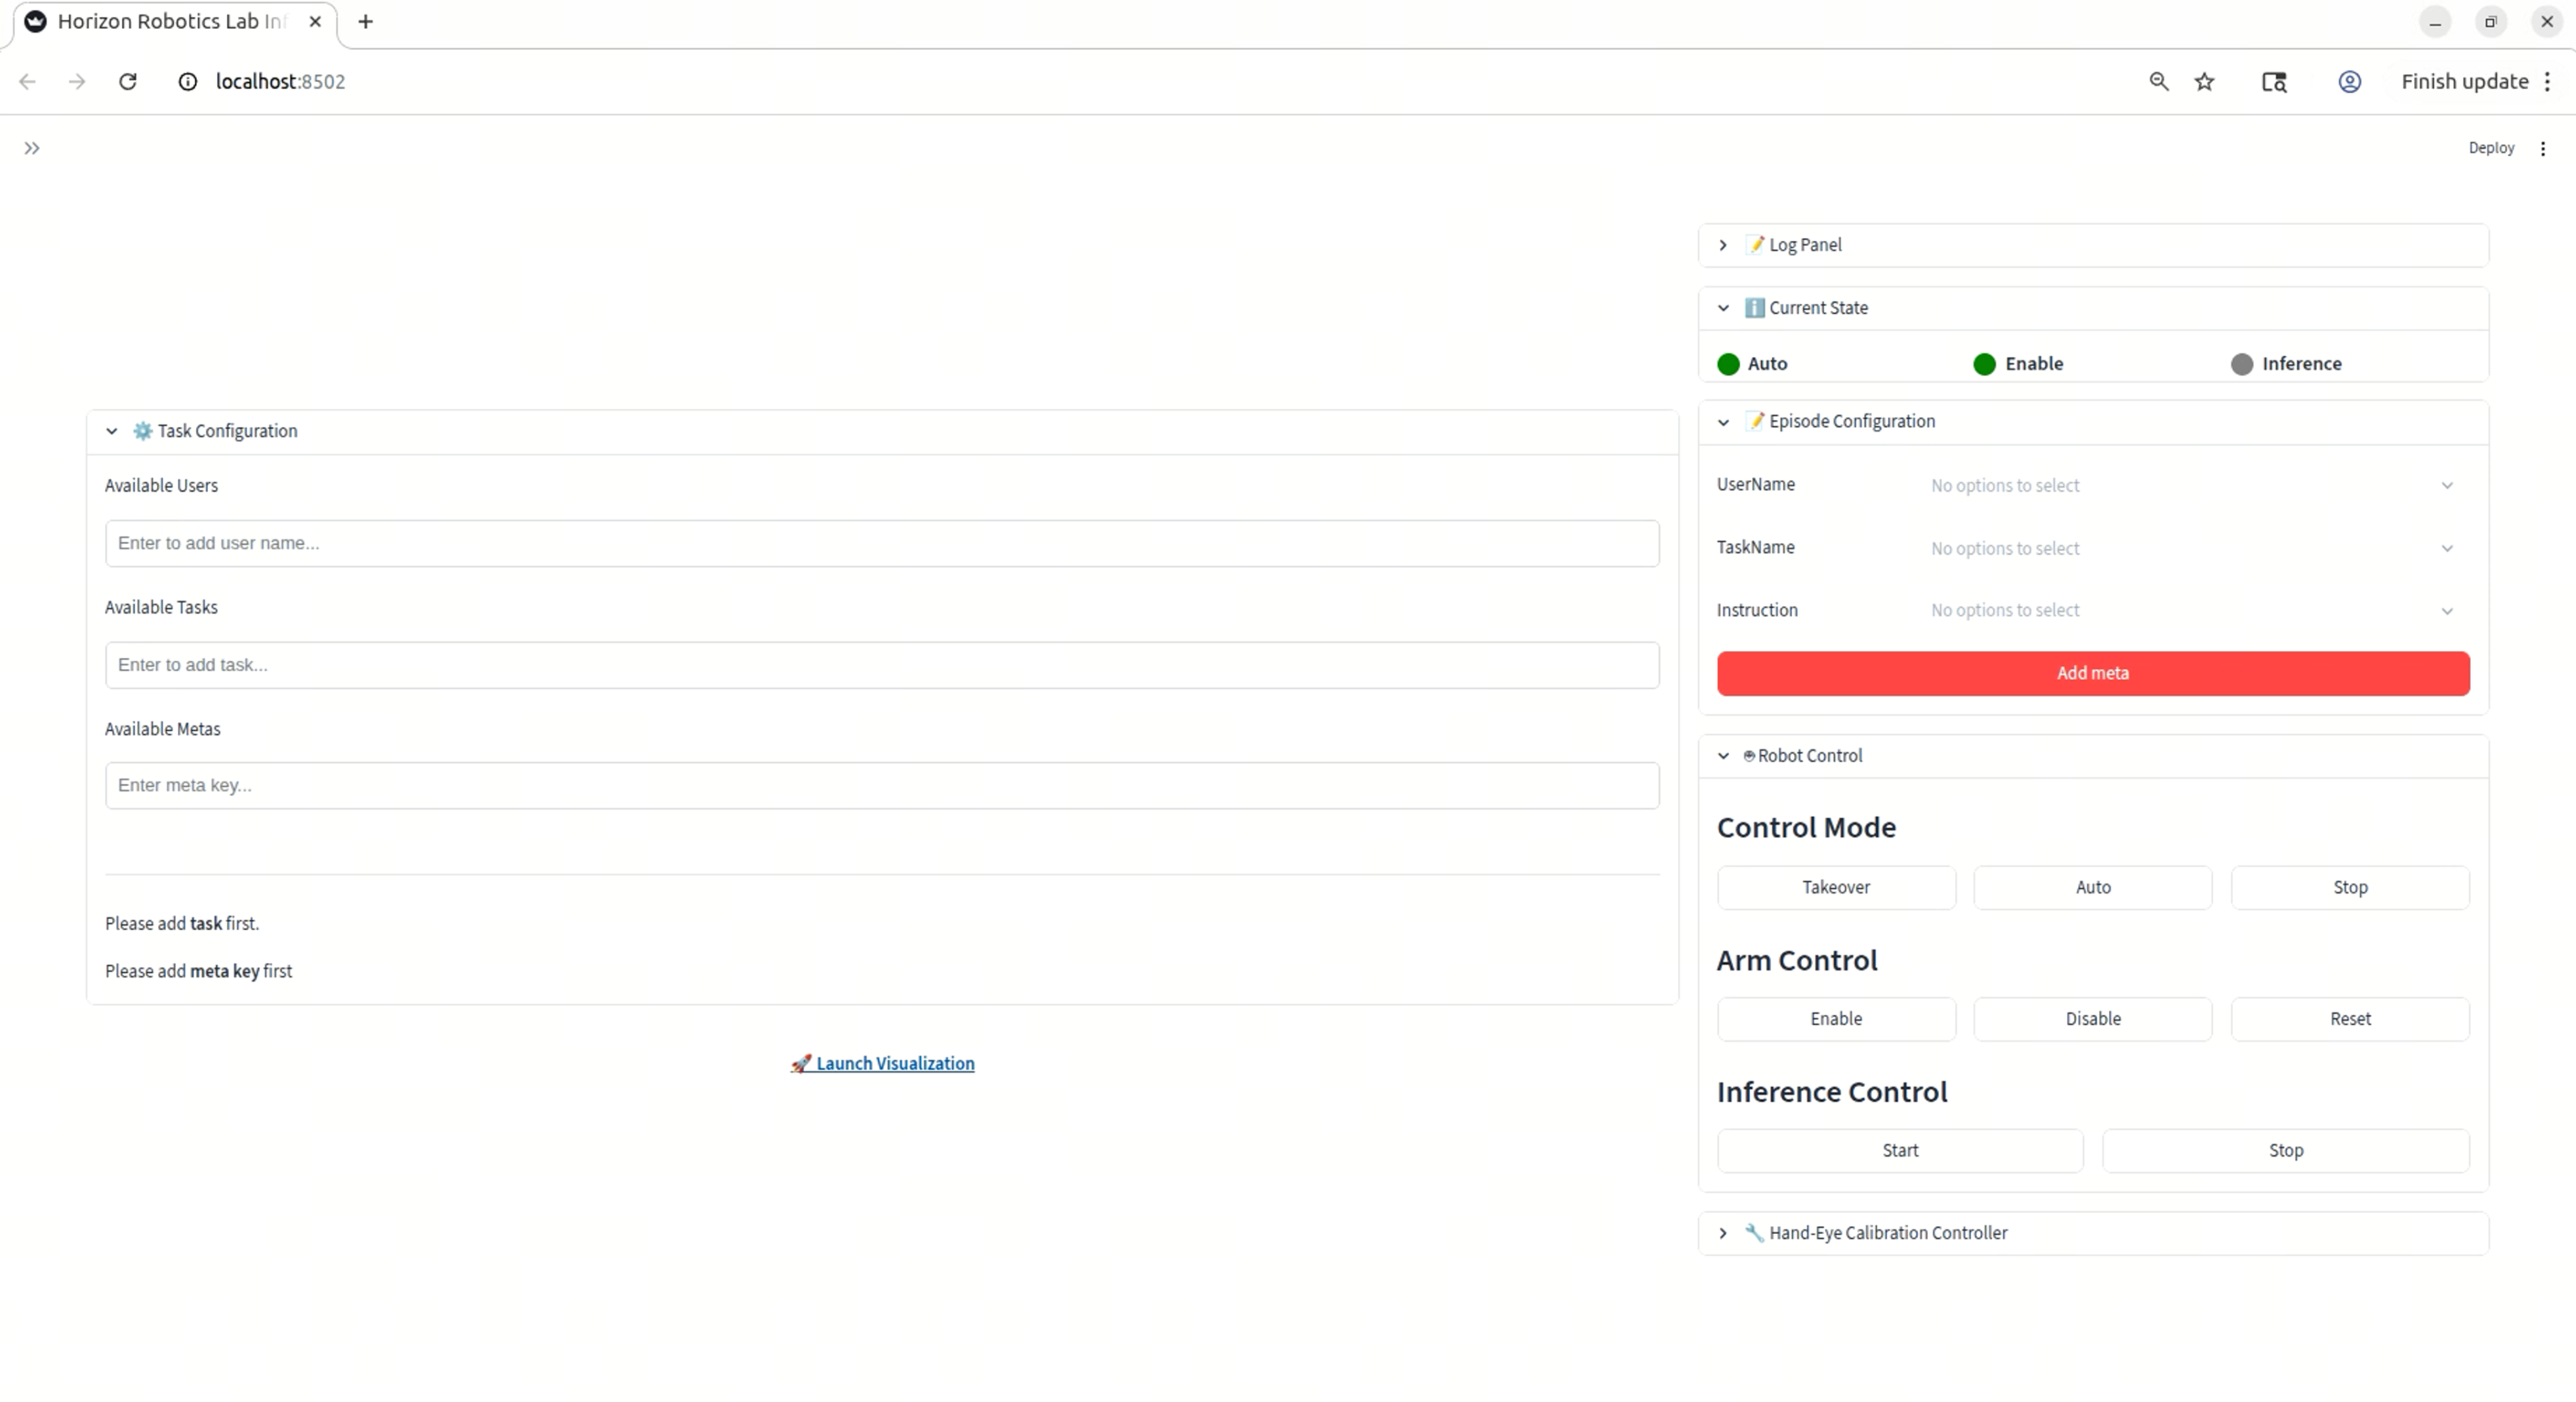
RoboOrchardApp Homepage